

Physically connected humanoids need consistent dynamics for internal actuator loops, inter-robot forces, and changing ground supports. We extend RoboCompiler with member-wise dynamics assembly, compiling reduced dynamics from rigid bodies, moving actuator parts, and reflected rotor inertias. Compiled body Jacobians and analytic constraint curvature yield an explicit Coriolis factor satisfying the power identity for floating-base quasi-velocities. A two-level reduction retains reusable robot models while composing their supports and hand connections; local inertial updates have rank at most six, and prescribed-acceleration constraint wrenches are affine in actuator efforts. These interfaces support actuator-aware tracking, coupled force allocation, payload updates, and support-mode switching for five hand-linked humanoids. Across 264 feasible states in eight humanoid configurations, normalised acceleration discrepancies remain within $1.6\!\times\!10^{-10}$ against a hard-constraint reference and $1.4\!\times\!10^{-10}$ against a compiler-independent reference; MuJoCo simulations achieve 0.73~mm root-mean-square (RMS) pelvis error in the ring dance and complete side steps through 20 support-mode changes.
翻译:暂无翻译


相关内容
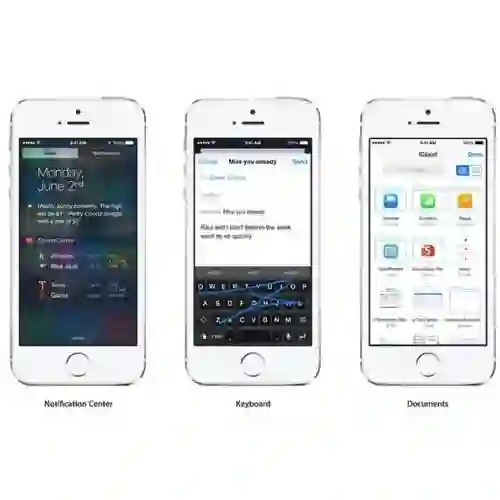
- Today (iOS and OS X): widgets for the Today view of Notification Center
- Share (iOS and OS X): post content to web services or share content with others
- Actions (iOS and OS X): app extensions to view or manipulate inside another app
- Photo Editing (iOS): edit a photo or video in Apple's Photos app with extensions from a third-party apps
- Finder Sync (OS X): remote file storage in the Finder with support for Finder content annotation
- Storage Provider (iOS): an interface between files inside an app and other apps on a user's device
- Custom Keyboard (iOS): system-wide alternative keyboards
Source: iOS 8 Extensions: Apple’s Plan for a Powerful App Ecosystem



 微信扫码咨询专知VIP会员