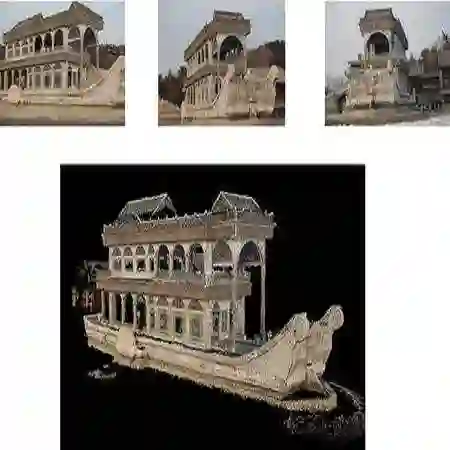
Streaming 3D reconstruction aims to recover 3D information, such as camera poses and point clouds, from a video stream, which necessitates geometric accuracy, temporal consistency, and computational efficiency. Motivated by the principles of Simultaneous Localization and Mapping (SLAM), we introduce LingBot-Map, a feed-forward 3D foundation model for reconstructing scenes from streaming data, built upon a geometric context transformer (GCT) architecture. A defining aspect of LingBot-Map lies in its carefully designed attention mechanism, which integrates an anchor context, a pose-reference window, and a trajectory memory to address coordinate grounding, dense geometric cues, and long-range drift correction, respectively. This design keeps the streaming state compact while retaining rich geometric context, enabling stable efficient inference at around 20 FPS on 518 x 378 resolution inputs over long sequences exceeding 10,000 frames. Extensive evaluations across a variety of benchmarks demonstrate that our approach achieves superior performance compared to both existing streaming and iterative optimization-based approaches.


翻译:暂无翻译

0
下载
关闭预览

相关内容

【牛津大学博士论文】学习理解大规模3D点云,191页pdf
专知会员服务
39+阅读 · 2023年6月22日
【CVPR2022】多视图聚合的大规模三维语义分割
专知会员服务
21+阅读 · 2022年4月20日
【SIGGRAPH2019】TensorFlow 2.0深度学习计算机图形学应用
专知会员服务
41+阅读 · 2019年10月9日
三维重建 3D reconstruction 有哪些实用算法?
极市平台
13+阅读 · 2020年2月23日
【泡泡点云时空】PointConv: 3D点云的深度卷积网络
泡泡机器人SLAM
23+阅读 · 2019年6月12日
【泡泡点云时空】FlowNet3D:学习三维点云中的场景流
泡泡机器人SLAM
41+阅读 · 2019年5月19日
目前最好的开源人脸3D重建与密集对齐算法
计算机视觉life
17+阅读 · 2019年4月24日
Unsupervised Learning via Meta-Learning
CreateAMind
44+阅读 · 2019年1月3日
国家自然科学基金
5+阅读 · 2017年12月31日
国家自然科学基金
9+阅读 · 2017年12月31日
国家自然科学基金
0+阅读 · 2015年12月31日
国家自然科学基金
0+阅读 · 2015年12月31日
国家自然科学基金
1+阅读 · 2015年12月31日
国家自然科学基金
2+阅读 · 2015年12月31日
国家自然科学基金
2+阅读 · 2015年12月31日
国家自然科学基金
0+阅读 · 2015年12月31日
国家自然科学基金
2+阅读 · 2014年12月31日
国家自然科学基金
1+阅读 · 2014年12月31日
Arxiv
12+阅读 · 2019年1月24日
VIP会员
最新内容
软件定义无人机蜂群给防空带来全新压力
专知会员服务
4+阅读 · 10月13日
《半自主无人地面战车的互操作性》66页
专知会员服务
5+阅读 · 10月13日
迈向更智慧的军事情报
专知会员服务
5+阅读 · 10月12日
《美国陆军2026年野战手册 2-0 情报》
专知会员服务
5+阅读 · 10月12日
《基于启发式算法求解武器-目标分配问题》
专知会员服务
7+阅读 · 10月12日
《美陆军最新条令出版物 2-0 情报》
专知会员服务
8+阅读 · 10月10日
电子战测试与训练靶场:战前验证战备状态
专知会员服务
3+阅读 · 10月10日
《美国陆军如何作战》46页最新报告
专知会员服务
9+阅读 · 10月10日
相关VIP内容
【牛津大学博士论文】学习理解大规模3D点云,191页pdf
专知会员服务
39+阅读 · 2023年6月22日
【CVPR2022】多视图聚合的大规模三维语义分割
专知会员服务
21+阅读 · 2022年4月20日
【SIGGRAPH2019】TensorFlow 2.0深度学习计算机图形学应用
专知会员服务
41+阅读 · 2019年10月9日
相关资讯
三维重建 3D reconstruction 有哪些实用算法?
极市平台
13+阅读 · 2020年2月23日
【泡泡点云时空】PointConv: 3D点云的深度卷积网络
泡泡机器人SLAM
23+阅读 · 2019年6月12日
【泡泡点云时空】FlowNet3D:学习三维点云中的场景流
泡泡机器人SLAM
41+阅读 · 2019年5月19日
目前最好的开源人脸3D重建与密集对齐算法
计算机视觉life
17+阅读 · 2019年4月24日
Unsupervised Learning via Meta-Learning
CreateAMind
44+阅读 · 2019年1月3日
相关基金
国家自然科学基金
5+阅读 · 2017年12月31日
国家自然科学基金
9+阅读 · 2017年12月31日
国家自然科学基金
0+阅读 · 2015年12月31日
国家自然科学基金
0+阅读 · 2015年12月31日
国家自然科学基金
1+阅读 · 2015年12月31日
国家自然科学基金
2+阅读 · 2015年12月31日
国家自然科学基金
2+阅读 · 2015年12月31日
国家自然科学基金
0+阅读 · 2015年12月31日
国家自然科学基金
2+阅读 · 2014年12月31日
国家自然科学基金
1+阅读 · 2014年12月31日
Top
微信扫码咨询专知VIP会员