

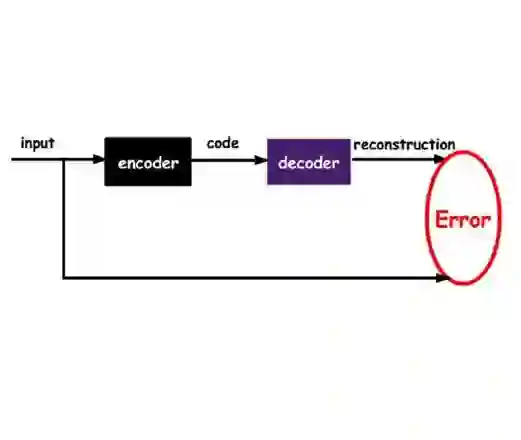
In the field of solid dynamics, knowing the corresponding modal basis of the system is capital, in order to improve design with respect to a desired dynamical behavior, such as avoiding natural frequencies at specific values or designing mechanical systems that can account for desired frequency spectrum. However, the determination of the modal basis involve the resolution of an eigenvalue problem, which can be expensive to perform for large systems, especially when dealing with a optimization of a parametric system design. In the present work, we propose to determine the parametrization of modal basis by considering an advanced Deep Learning technique based on the Rank Reduction AutoEncoder (RRAE). The RRAE is based on an autoencoder whose latent space is constrained through a truncated Singular Value Decomposition (SVD) approximation. This formulation enables the latent space to capture the dominant features of the data efficiently. As a result, the autoencoder is guided toward learning the underlying physical behavior represented across the dataset, mitigating overfitting and spurious predictions. The main idea consists of identifying a reduced parameter space using the RRAE for the first eigenvector, while the remaining modes are subsequently reconstructed through neural networks that take the same reduced parameter space as input, thereby coupling all modes in a nonlinear parametric framework. The proposed architecture is validated through the parametrization of the modal basis in 1D and 2D problems.
翻译:暂无翻译


相关内容



 微信扫码咨询专知VIP会员