

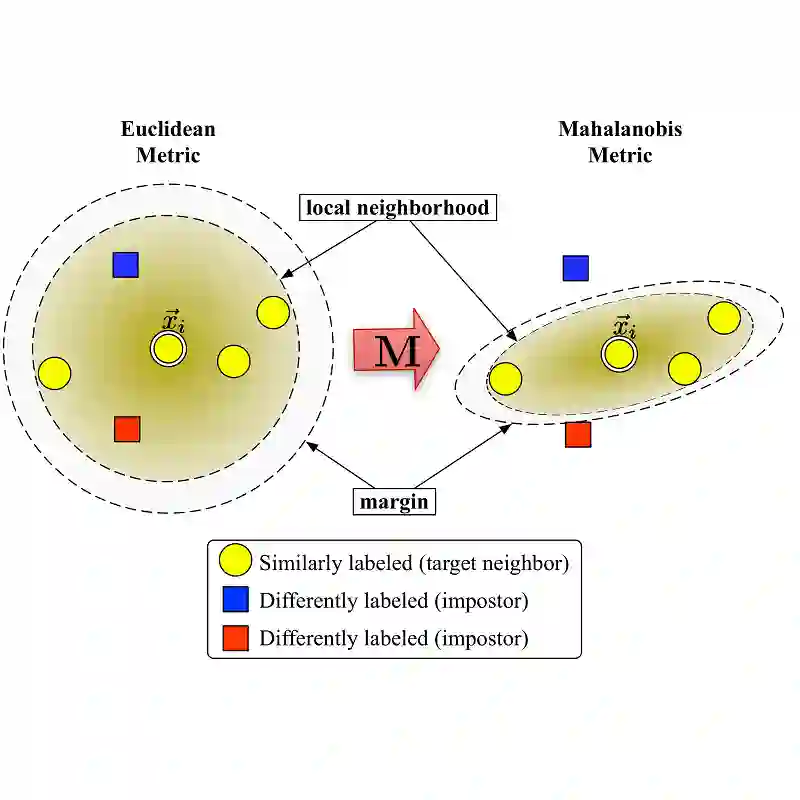
We propose a novel clustering approach for point-cloud segmentation based on supervised contrastive metric learning (CML). Rather than predicting cluster assignments or object-centric variables, the method learns a latent representation in which points belonging to the same object are embedded nearby while unrelated points are separated. Clusters are then reconstructed using a density-based readout in the learned metric space, decoupling representation learning from cluster formation and enabling flexible inference. The approach is evaluated on simulated data from a highly granular calorimeter, where the task is to separate highly overlapping particle showers represented as sets of calorimeter hits. A direct comparison with object condensation (OC) is performed using identical graph neural network backbones and equal latent dimensionality, isolating the effect of the learning objective. The CML method produces a more stable and separable embedding geometry for both electromagnetic and hadronic particle showers, leading to improved local neighbourhood consistency, a more reliable separation of overlapping showers, and better generalization when extrapolating to unseen multiplicities and energies. This translates directly into higher reconstruction efficiency and purity, particularly in high-multiplicity regimes, as well as improved energy resolution. In mixed-particle environments, CML maintains strong performance, suggesting robust learning of the shower topology, while OC exhibits significant degradation. These results demonstrate that similarity-based representation learning combined with density-based aggregation is a promising alternative to object-centric approaches for point cloud segmentation in highly granular detectors.
翻译:暂无翻译


相关内容



 微信扫码咨询专知VIP会员