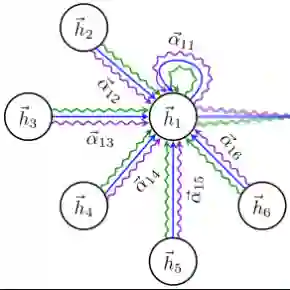
This paper presents a graph-based safe multi-agent reinforcement learning (MARL) framework for cooperative navigation with time-varying topology. To address the critical challenge of ensuring safety in environments with sensing constraints, a safety-decoupled mechanism is introduced through a Control Barrier-Like Function (CBLF) action screening layer. This mechanism bridges the gap between discrete LiDAR perception and continuous safety constraints, ensuring that physical safety constraints are strictly satisfied regardless of the learning progress. Building upon this safety foundation, a unified structural architecture is proposed, integrating a attention-based actor and a Graph Attention Network (GAT) centralized critic. The actor utilizes a value vector reconstruction mechanism that explicitly encodes relative geometric relations through a collaborative tracking error matrix, enabling scale-insensitive policy learning under time-varying communication topologies. Meanwhile, the GAT-based critic models evolving interaction structures for accurate global value estimation. The proposed framework is validated on real differential-drive robot platforms, and experimental results demonstrate superior stability and safety in dynamic scenarios with limited fields-of-view.


翻译:暂无翻译

0
下载
关闭预览

相关内容

专知会员服务
175+阅读 · 2021年8月3日
【斯坦福大学】Gradient Surgery for Multi-Task Learning
专知会员服务
47+阅读 · 2020年1月23日
Stabilizing Transformers for Reinforcement Learning
专知会员服务
61+阅读 · 2019年10月17日
多智能体强化学习(MARL)近年研究概览
PaperWeekly
39+阅读 · 2020年3月15日
Hierarchically Structured Meta-learning
CreateAMind
27+阅读 · 2019年5月22日
强化学习的Unsupervised Meta-Learning
CreateAMind
18+阅读 · 2019年1月7日
Unsupervised Learning via Meta-Learning
CreateAMind
44+阅读 · 2019年1月3日
李宏毅-201806-中文-Deep Reinforcement Learning精品课程分享
深度学习与NLP
15+阅读 · 2018年6月20日
国家自然科学基金
3+阅读 · 2015年12月31日
国家自然科学基金
1+阅读 · 2015年12月31日
国家自然科学基金
0+阅读 · 2015年12月31日
国家自然科学基金
1+阅读 · 2015年12月31日
国家自然科学基金
2+阅读 · 2015年12月31日
国家自然科学基金
17+阅读 · 2014年12月31日
国家自然科学基金
19+阅读 · 2012年12月31日
国家自然科学基金
19+阅读 · 2012年12月31日
国家自然科学基金
24+阅读 · 2011年12月31日
国家自然科学基金
19+阅读 · 2008年12月31日
A Multi-Objective Deep Reinforcement Learning Framework
VIP会员
最新内容
软件定义无人机蜂群给防空带来全新压力
专知会员服务
4+阅读 · 10月13日
《半自主无人地面战车的互操作性》66页
专知会员服务
5+阅读 · 10月13日
迈向更智慧的军事情报
专知会员服务
5+阅读 · 10月12日
《美国陆军2026年野战手册 2-0 情报》
专知会员服务
5+阅读 · 10月12日
《基于启发式算法求解武器-目标分配问题》
专知会员服务
7+阅读 · 10月12日
《美陆军最新条令出版物 2-0 情报》
专知会员服务
8+阅读 · 10月10日
电子战测试与训练靶场:战前验证战备状态
专知会员服务
3+阅读 · 10月10日
《美国陆军如何作战》46页最新报告
专知会员服务
9+阅读 · 10月10日
相关VIP内容
专知会员服务
175+阅读 · 2021年8月3日
【斯坦福大学】Gradient Surgery for Multi-Task Learning
专知会员服务
47+阅读 · 2020年1月23日
Stabilizing Transformers for Reinforcement Learning
专知会员服务
61+阅读 · 2019年10月17日
相关基金
国家自然科学基金
3+阅读 · 2015年12月31日
国家自然科学基金
1+阅读 · 2015年12月31日
国家自然科学基金
0+阅读 · 2015年12月31日
国家自然科学基金
1+阅读 · 2015年12月31日
国家自然科学基金
2+阅读 · 2015年12月31日
国家自然科学基金
17+阅读 · 2014年12月31日
国家自然科学基金
19+阅读 · 2012年12月31日
国家自然科学基金
19+阅读 · 2012年12月31日
国家自然科学基金
24+阅读 · 2011年12月31日
国家自然科学基金
19+阅读 · 2008年12月31日
Top
微信扫码咨询专知VIP会员