

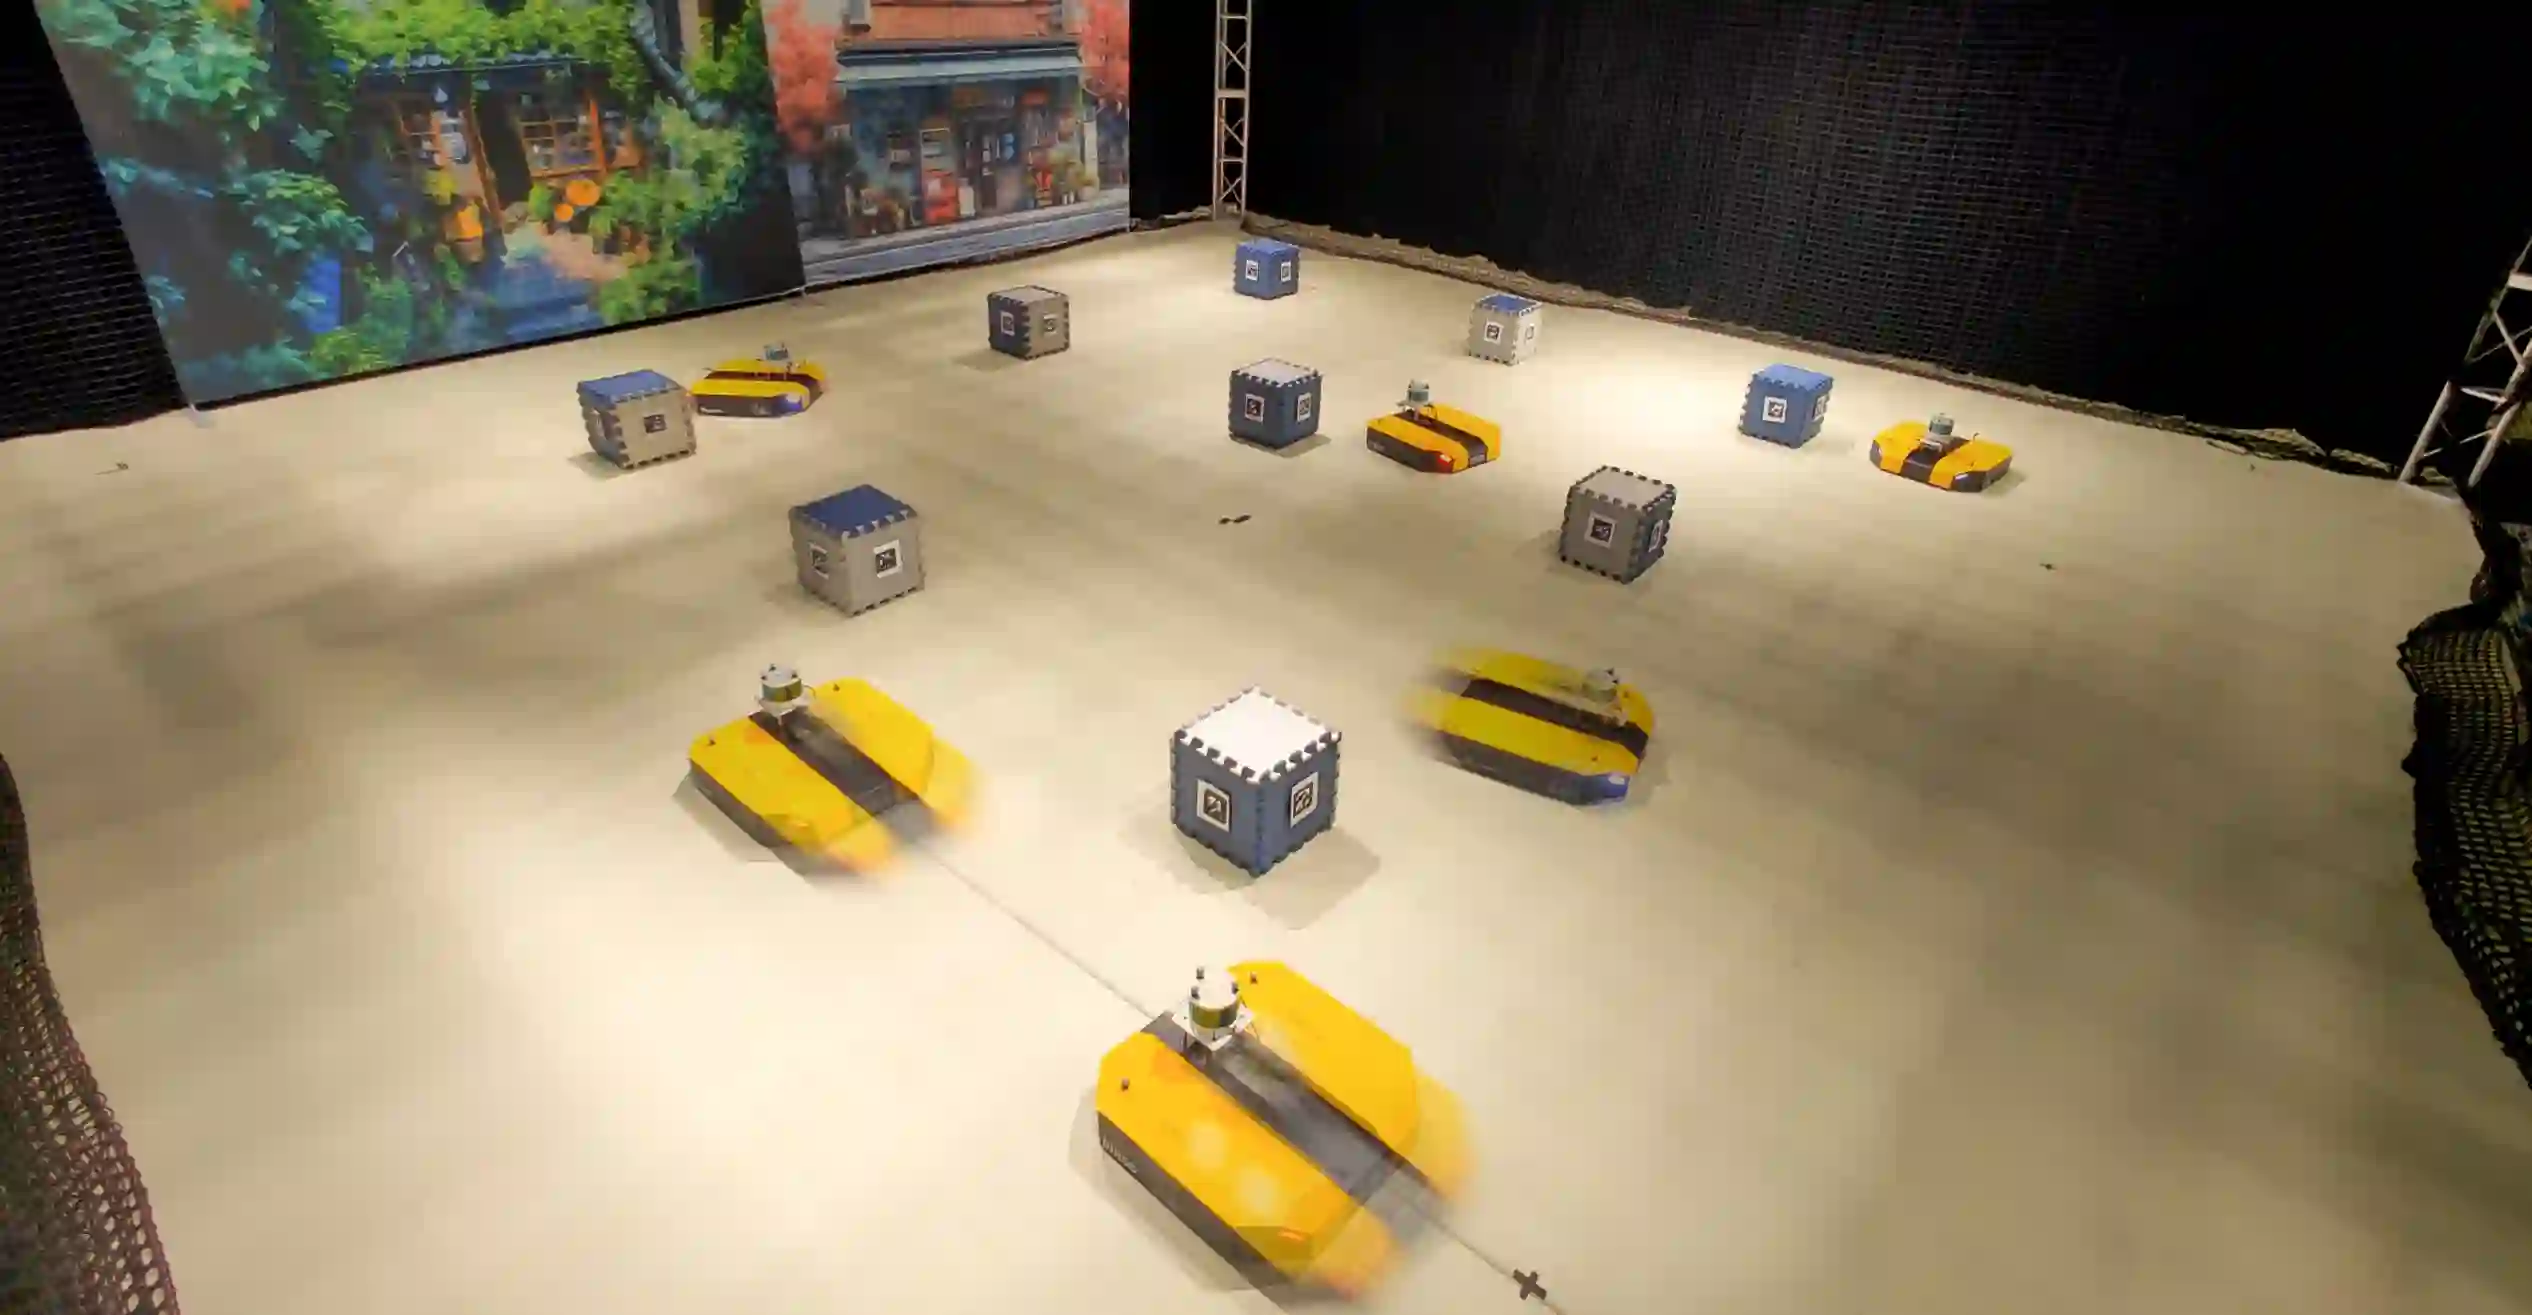
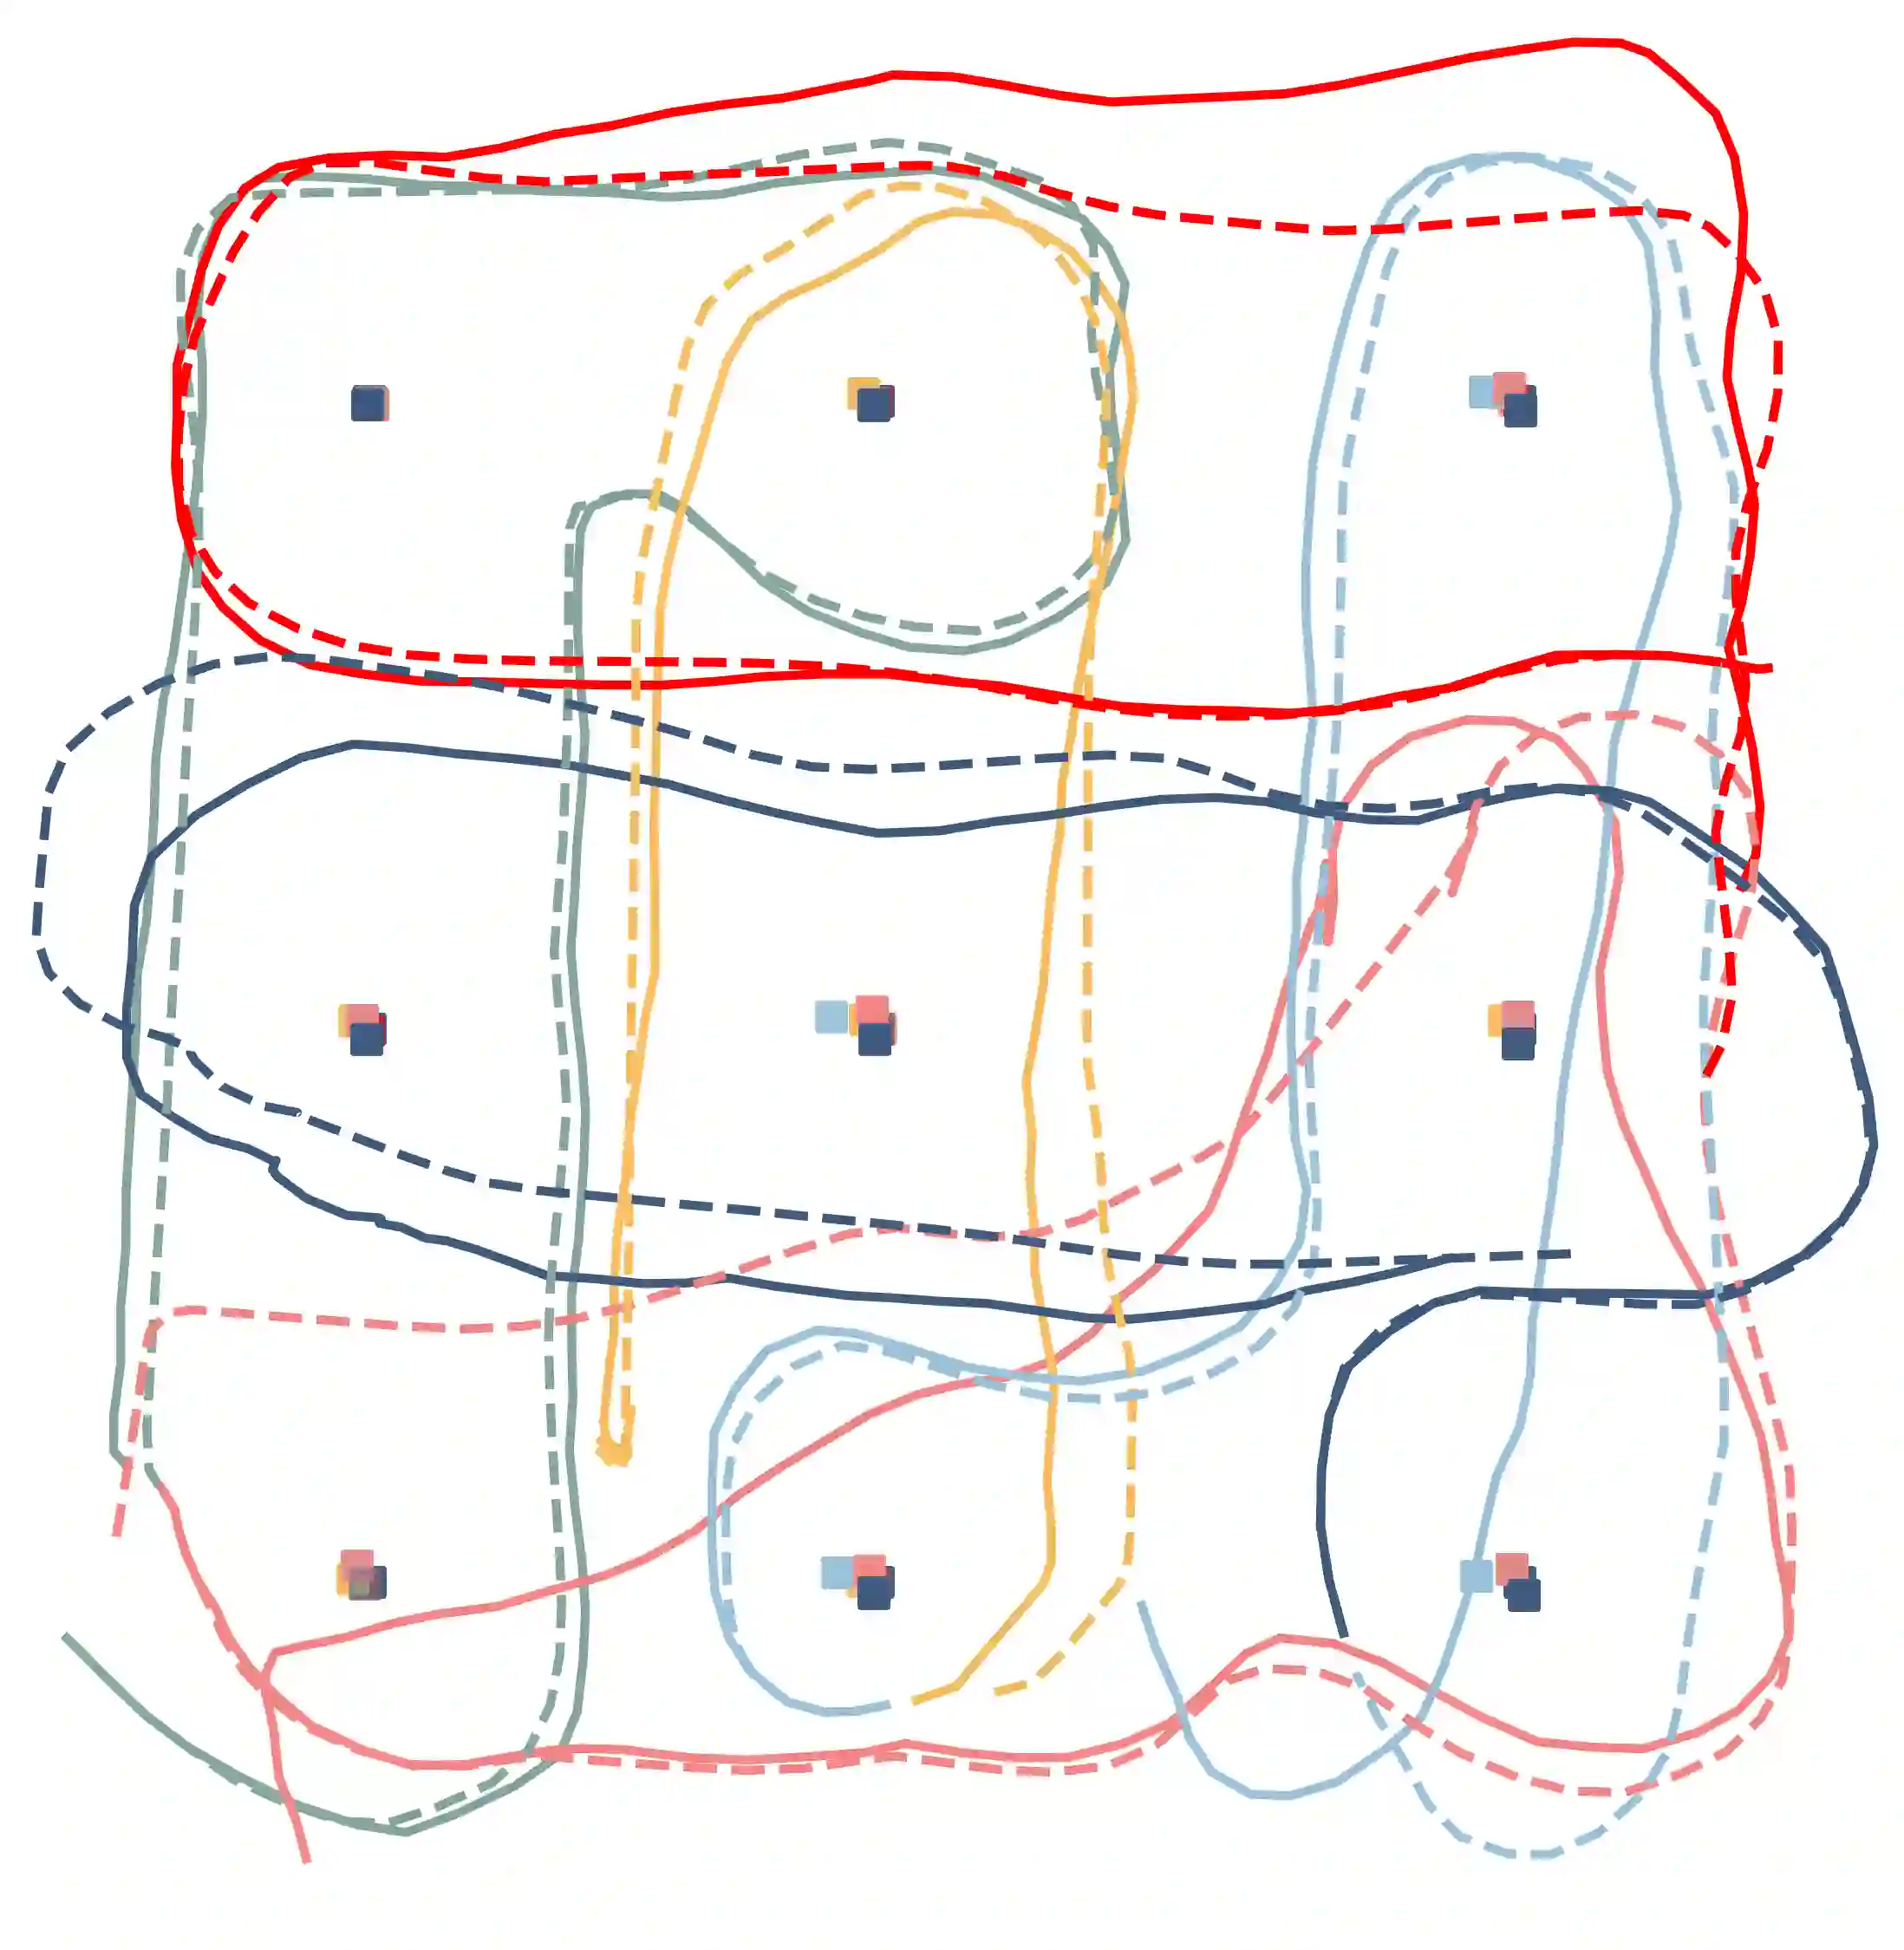
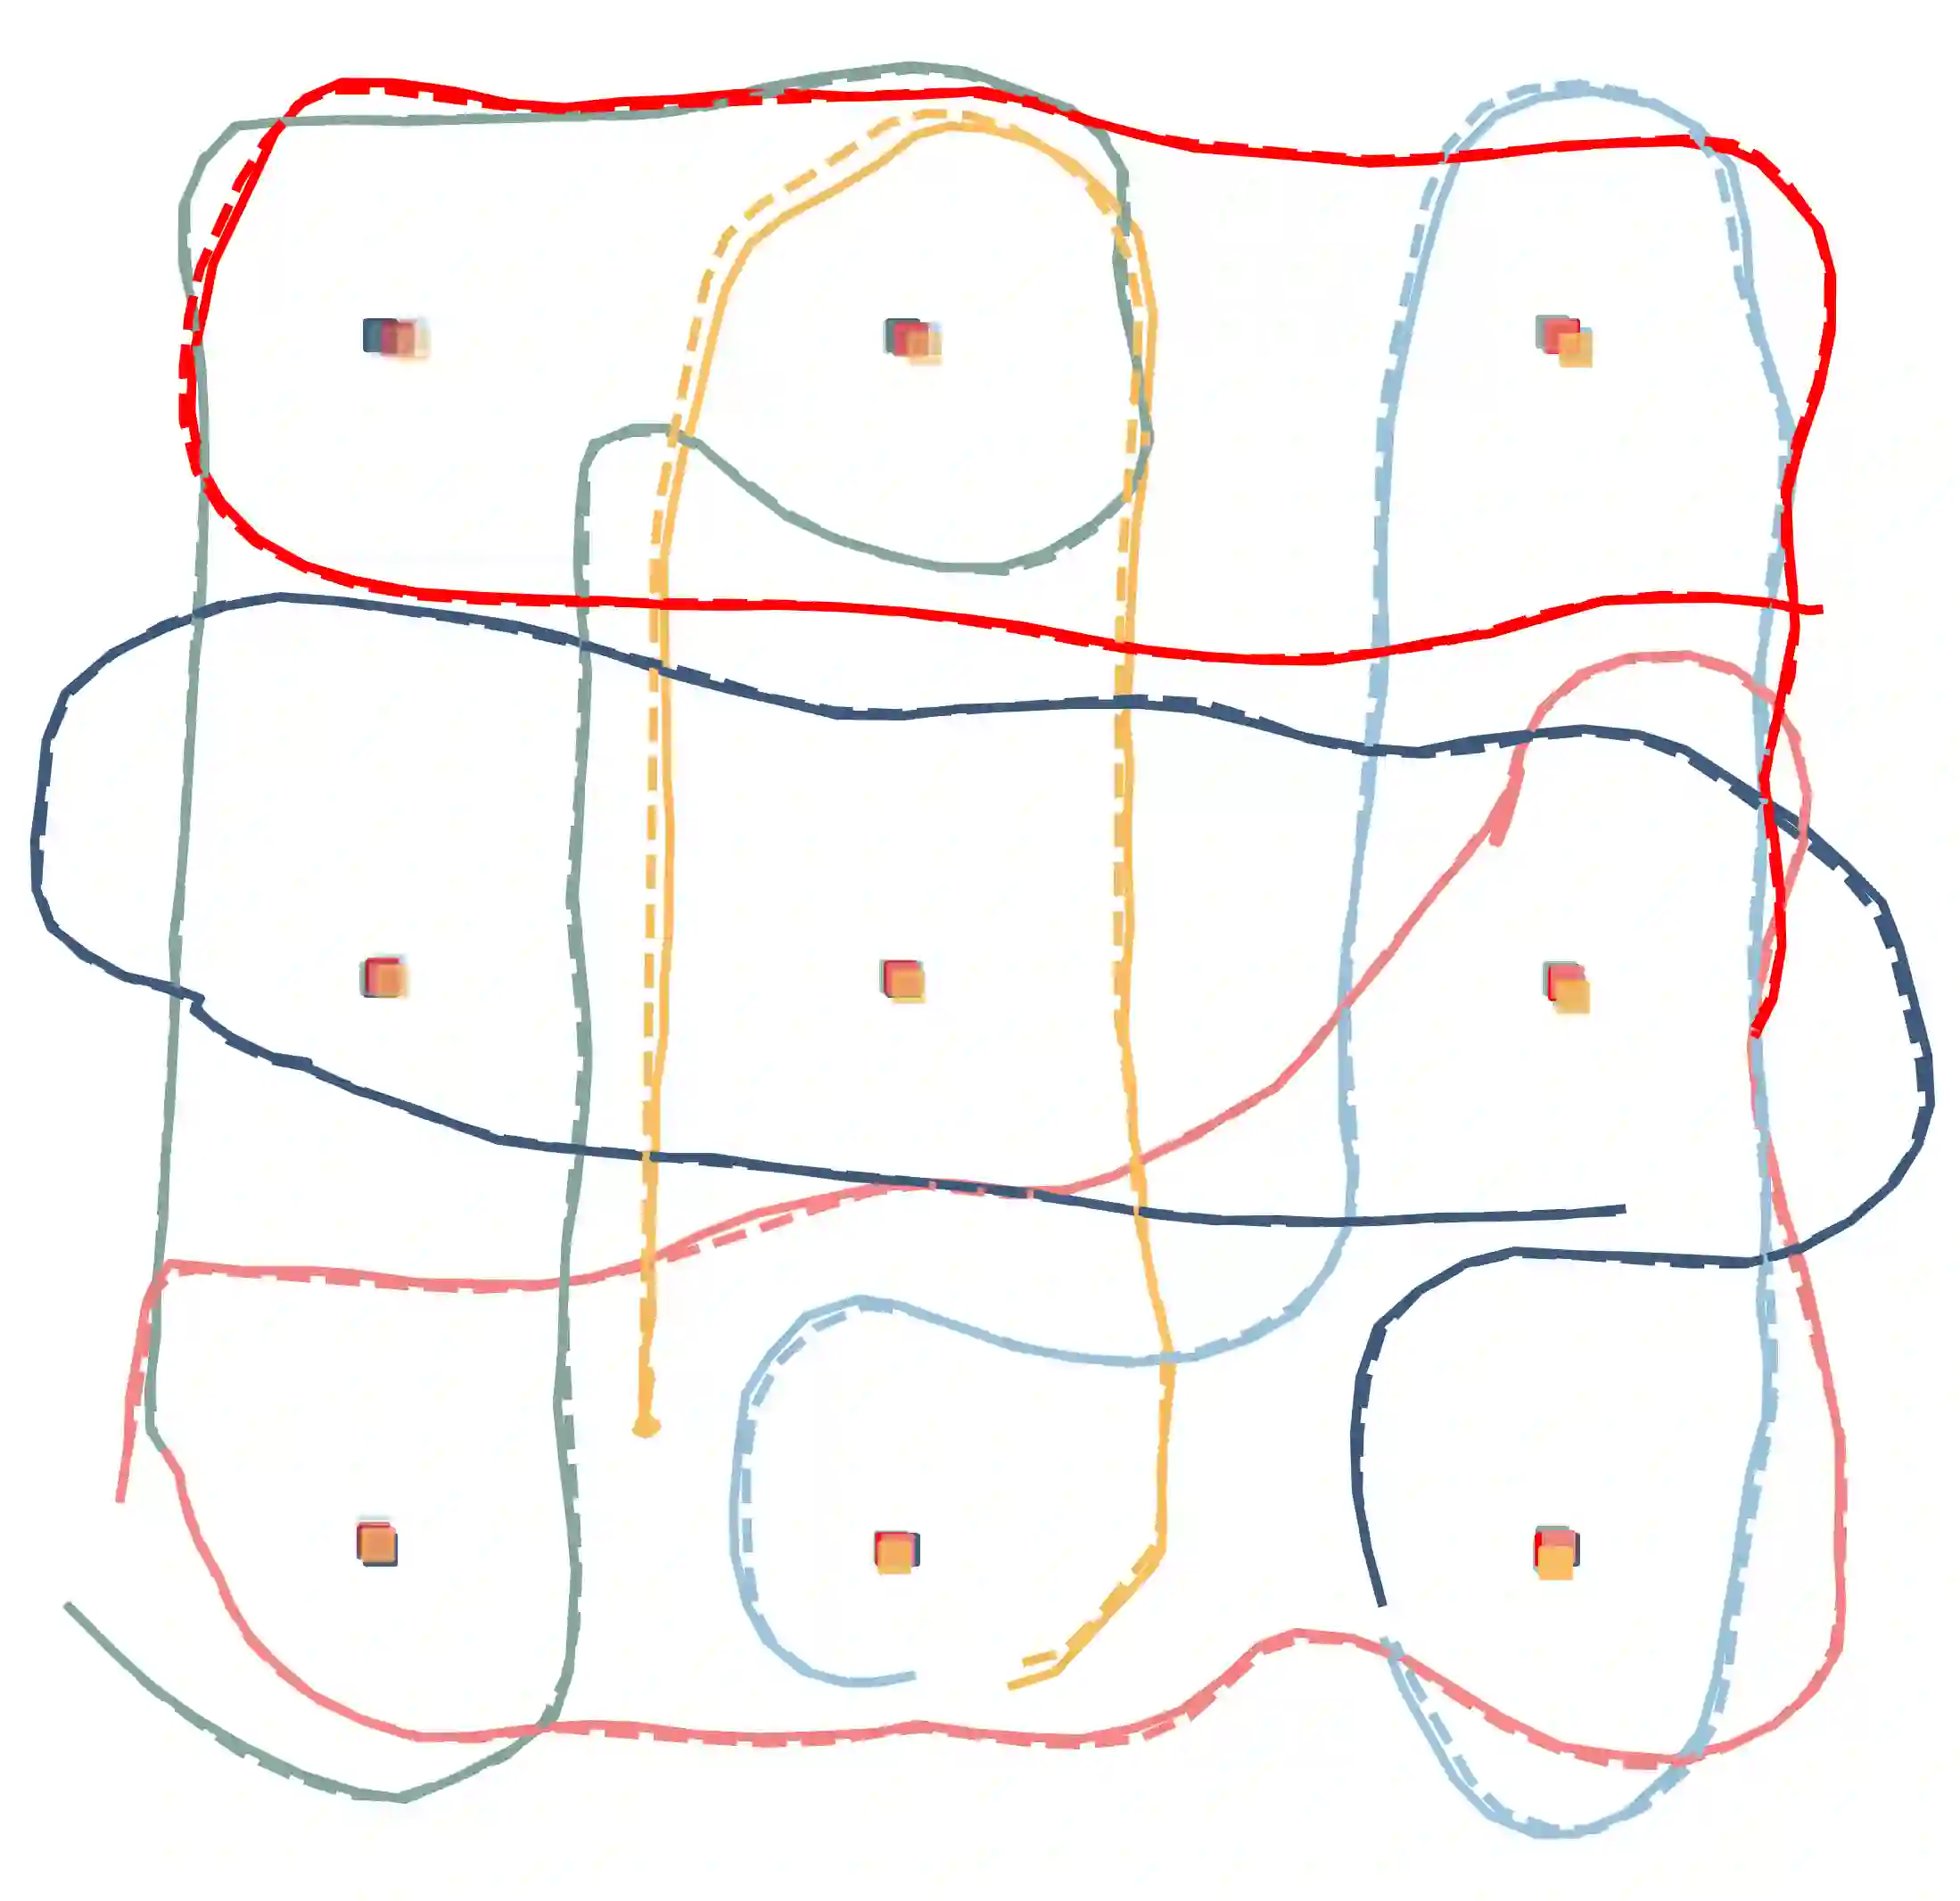
Pose graph optimization (PGO) is a key back-end component for state estimation in networked multi-robot simultaneous localization and mapping (SLAM). In object-based multi-robot SLAM, the problem becomes more tightly coupled because robots must jointly estimate both their trajectories and the poses of persistent objects observed by multiple agents. Existing decentralized solutions often assume that the communication graph closely matches the physical interaction topology, which is restrictive in realistic deployments where communication is sparse, intermittent, or time-varying. This paper presents a fully decentralized Riemannian optimization framework for object-based multi-robot PGO that decouples the coupled estimation problem via a consensus mechanism, enabling flexible communication topologies. To improve convergence under limited communication budgets, we further develop a distributed approximate-Newton scheme that exploits local second-order information while operating directly on the SE(d) manifold to preserve geometric consistency, and we establish the convergence to Riemannian first-order stationary points and provide a local condition-number analysis explaining the benefit of approximate second-order information over first-order Riemannian descent. The resulting method reduces iteration count and communication overhead without sacrificing estimation accuracy. Extensive evaluations on public benchmarks, large-scale simulations, and real-world multi-robot experiments demonstrate improved accuracy, runtime efficiency, scalability across network topologies, and robustness to communication failures.
翻译:暂无翻译


相关内容




 微信扫码咨询专知VIP会员