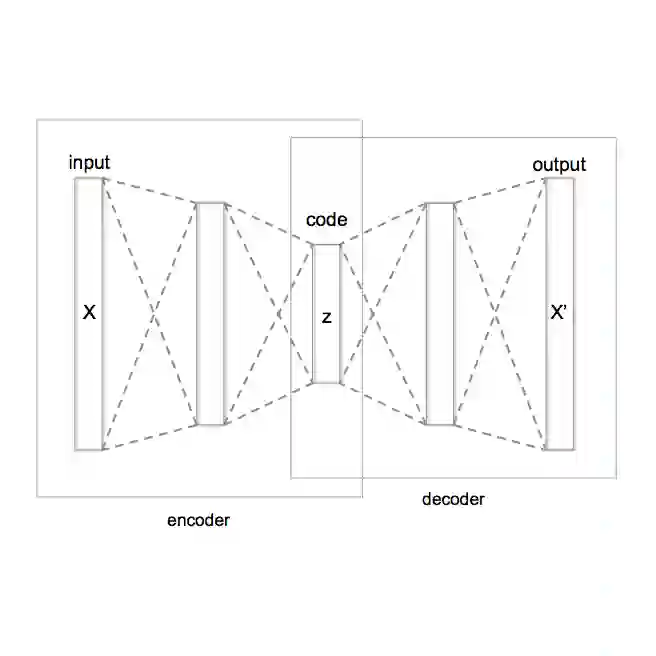
The challenges inherent to long-horizon tasks in robotics persist due to the typical inefficient exploration and sparse rewards in traditional reinforcement learning approaches. To alleviate these challenges, we introduce a novel algorithm, Variational Autoencoder-based Subgoal Inference (VAESI), to accomplish long-horizon tasks through a divide-and-conquer manner. VAESI consists of three components: a Variational Autoencoder (VAE)-based Subgoal Generator, a Hindsight Sampler, and a Value Selector. The VAE-based Subgoal Generator draws inspiration from the human capacity to infer subgoals and reason about the final goal in the context of these subgoals. It is composed of an explicit encoder model, engineered to generate subgoals, and an implicit decoder model, designed to enhance the quality of the generated subgoals by predicting the final goal. Additionally, the Hindsight Sampler selects valid subgoals from an offline dataset to enhance the feasibility of the generated subgoals. The Value Selector utilizes the value function in reinforcement learning to filter the optimal subgoals from subgoal candidates. To validate our method, we conduct several long-horizon tasks in both simulation and the real world, including one locomotion task and three manipulation tasks. The obtained quantitative and qualitative data indicate that our approach achieves promising performance compared to other baseline methods. These experimental results can be seen in the website \url{https://sites.google.com/view/vaesi/home}.


翻译:针对长期任务中传统强化学习方法普遍存在的探索效率低下和奖励稀疏问题,本文提出了一种新型算法——基于变分自编码器的子目标推理(VAESI),通过"分而治之"策略完成长期任务。VAESI包含三个核心组件:基于变分自编码器(VAE)的子目标生成器、事后采样器和价值选择器。其中,VAE子目标生成器借鉴人类推断子目标并基于子目标推理最终目标的能力,由显式编码器模型(用于生成子目标)和隐式解码器模型(通过预测最终目标提升子目标生成质量)构成。事后采样器从离线数据集中筛选有效子目标以增强生成子目标的可行性,价值选择器则利用强化学习中的价值函数从候选子目标中筛选最优子目标。为验证该方法,我们在仿真环境和真实场景中开展了包含1个移动任务和3个操作任务的长期实验。定性与定量结果表明,与基线方法相比,本方法取得了显著性能提升。完整实验数据详见项目网站:\url{https://sites.google.com/view/vaesi/home}。

0
下载
关闭预览

相关内容

FlowQA: Grasping Flow in History for Conversational Machine Comprehension
专知会员服务
35+阅读 · 2019年10月18日
Stabilizing Transformers for Reinforcement Learning
专知会员服务
61+阅读 · 2019年10月17日
《DeepGCNs: Making GCNs Go as Deep as CNNs》
专知会员服务
32+阅读 · 2019年10月17日
Keras François Chollet 《Deep Learning with Python 》, 386页pdf
专知会员服务
164+阅读 · 2019年10月12日
【SIGGRAPH2019】TensorFlow 2.0深度学习计算机图形学应用
专知会员服务
41+阅读 · 2019年10月9日
Hierarchically Structured Meta-learning
CreateAMind
27+阅读 · 2019年5月22日
Transferring Knowledge across Learning Processes
CreateAMind
29+阅读 · 2019年5月18日
Unsupervised Learning via Meta-Learning
CreateAMind
44+阅读 · 2019年1月3日
meta learning 17年:MAML SNAIL
CreateAMind
11+阅读 · 2019年1月2日
A Technical Overview of AI & ML in 2018 & Trends for 2019
待字闺中
18+阅读 · 2018年12月24日
STRCF for Visual Object Tracking
统计学习与视觉计算组
15+阅读 · 2018年5月29日
Hierarchical Imitation - Reinforcement Learning
CreateAMind
19+阅读 · 2018年5月25日
Focal Loss for Dense Object Detection
统计学习与视觉计算组
12+阅读 · 2018年3月15日
IJCAI | Cascade Dynamics Modeling with Attention-based RNN
KingsGarden
13+阅读 · 2017年7月16日
From Softmax to Sparsemax-ICML16(1)
KingsGarden
74+阅读 · 2016年11月26日
国家自然科学基金
2+阅读 · 2017年12月31日
国家自然科学基金
13+阅读 · 2017年12月31日
国家自然科学基金
2+阅读 · 2015年12月31日
国家自然科学基金
47+阅读 · 2015年12月31日
国家自然科学基金
2+阅读 · 2015年12月31日
国家自然科学基金
3+阅读 · 2015年12月31日
国家自然科学基金
0+阅读 · 2014年12月31日
国家自然科学基金
0+阅读 · 2014年12月31日
国家自然科学基金
0+阅读 · 2014年12月31日
国家自然科学基金
2+阅读 · 2014年12月31日
VIP会员
最新内容
现代电磁战:集成式系统簇时代如何实现频谱优势
综述|谁来改进机器人?迈向物理递归自我改进
专知会员服务
0+阅读 · 今天14:47
软件定义无人机蜂群给防空带来全新压力
专知会员服务
9+阅读 · 10月13日
《半自主无人地面战车的互操作性》66页
专知会员服务
9+阅读 · 10月13日
迈向更智慧的军事情报
专知会员服务
9+阅读 · 10月12日
《美国陆军2026年野战手册 2-0 情报》
专知会员服务
8+阅读 · 10月12日
《基于启发式算法求解武器-目标分配问题》
专知会员服务
9+阅读 · 10月12日
相关资讯
Hierarchically Structured Meta-learning
CreateAMind
27+阅读 · 2019年5月22日
Transferring Knowledge across Learning Processes
CreateAMind
29+阅读 · 2019年5月18日
Unsupervised Learning via Meta-Learning
CreateAMind
44+阅读 · 2019年1月3日
meta learning 17年:MAML SNAIL
CreateAMind
11+阅读 · 2019年1月2日
A Technical Overview of AI & ML in 2018 & Trends for 2019
待字闺中
18+阅读 · 2018年12月24日
STRCF for Visual Object Tracking
统计学习与视觉计算组
15+阅读 · 2018年5月29日
Hierarchical Imitation - Reinforcement Learning
CreateAMind
19+阅读 · 2018年5月25日
Focal Loss for Dense Object Detection
统计学习与视觉计算组
12+阅读 · 2018年3月15日
IJCAI | Cascade Dynamics Modeling with Attention-based RNN
KingsGarden
13+阅读 · 2017年7月16日
From Softmax to Sparsemax-ICML16(1)
KingsGarden
74+阅读 · 2016年11月26日
相关基金
国家自然科学基金
2+阅读 · 2017年12月31日
国家自然科学基金
13+阅读 · 2017年12月31日
国家自然科学基金
2+阅读 · 2015年12月31日
国家自然科学基金
47+阅读 · 2015年12月31日
国家自然科学基金
2+阅读 · 2015年12月31日
国家自然科学基金
3+阅读 · 2015年12月31日
国家自然科学基金
0+阅读 · 2014年12月31日
国家自然科学基金
0+阅读 · 2014年12月31日
国家自然科学基金
0+阅读 · 2014年12月31日
国家自然科学基金
2+阅读 · 2014年12月31日
Top
微信扫码咨询专知VIP会员