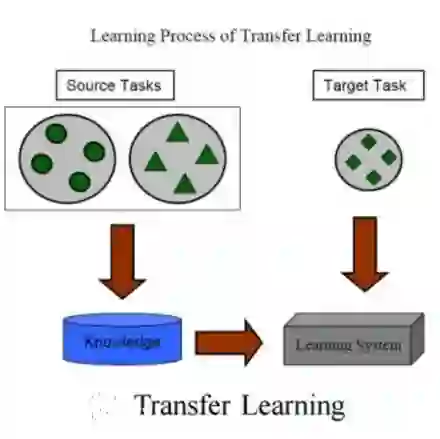
In material characterization, identifying defective areas on a material surface is fundamental. The conventional approach involves measuring the relevant physical properties point-by-point at the predetermined mesh grid points on the surface and determining the area at which the property does not reach the desired level. To identify defective areas more efficiently, we propose adaptive mapping methods in which measurement resources are used preferentially to detect the boundaries of defective areas. We interpret this problem as an active-learning (AL) of the level set estimation (LSE) problem. The goal of AL-based LSE is to determine the level set of the physical property function defined on the surface with as small number of measurements as possible. Furthermore, to handle the situations in which materials with similar specifications are repeatedly produced, we introduce a transfer learning approach so that the information of previously produced materials can be effectively utilized. As a proof-of-concept, we applied the proposed methods to the red-zone estimation problem of silicon wafers and demonstrated that we could identify the defective areas with significantly lower measurement costs than those of conventional methods.


翻译:在材料表征中,识别材料表面的缺陷区域是基础性工作。传统方法是在表面预设网格点上逐点测量相关物理特性,并确定特性未达到期望水平的区域。为更高效地识别缺陷区域,我们提出自适应映射方法,优先将测量资源用于检测缺陷区域的边界。我们将该问题解释为水平集估计问题的主动学习。基于主动学习的水平集估计目标是以尽可能少的测量次数确定表面物理特性函数的水平集。此外,为处理规格相近材料重复生产的情况,我们引入迁移学习方法,使先前生产材料的信息能被有效利用。作为概念验证,我们将所提方法应用于硅晶圆红区估计问题,并证明相较于传统方法,我们能以显著更低的测量成本识别缺陷区域。


0
下载
关闭预览

相关内容

不可错过!《机器学习100讲》课程,UBC Mark Schmidt讲授
专知会员服务
76+阅读 · 2022年6月28日
【CVPR2022】多机器人协同主动建图算法
专知会员服务
50+阅读 · 2022年4月3日
专知会员服务
21+阅读 · 2021年4月2日
零样本文本分类,Zero-Shot Learning for Text Classification
专知会员服务
97+阅读 · 2020年5月31日
【阿里巴巴-CVPR2020】频域学习,Learning in the Frequency Domain
【泡泡汇总】CVPR2019 SLAM Paperlist
泡泡机器人SLAM
14+阅读 · 2019年6月12日
Transferring Knowledge across Learning Processes
CreateAMind
29+阅读 · 2019年5月18日
逆强化学习-学习人先验的动机
CreateAMind
16+阅读 · 2019年1月18日
【泡泡一分钟】基于运动估计的激光雷达和相机标定方法
泡泡机器人SLAM
25+阅读 · 2019年1月17日
【推荐】深度学习目标检测概览
机器学习研究会
10+阅读 · 2017年9月1日
国家自然科学基金
3+阅读 · 2015年12月31日
国家自然科学基金
0+阅读 · 2013年12月31日
国家自然科学基金
3+阅读 · 2013年12月31日
国家自然科学基金
1+阅读 · 2012年12月31日
国家自然科学基金
0+阅读 · 2011年12月31日
国家自然科学基金
0+阅读 · 2011年12月31日
国家自然科学基金
0+阅读 · 2011年12月31日
国家自然科学基金
0+阅读 · 2009年12月31日
Arxiv
0+阅读 · 2023年5月23日
Arxiv
29+阅读 · 2021年11月2日
Arxiv
14+阅读 · 2021年7月20日
VIP会员
最新内容
世界模型入门:从序贯决策到通用智能体
专知会员服务
6+阅读 · 10月24日
军事域更好使用人工智能的实用指南
专知会员服务
9+阅读 · 10月22日
《衡量语言模型中的作战规划能力》
专知会员服务
14+阅读 · 10月20日
Maven智能系统:帕兰提尔军事人工智能平台详解
专知会员服务
17+阅读 · 10月20日
《测试自动化框架在敏捷软件开发中的角色》
专知会员服务
9+阅读 · 10月20日
俄罗斯如何拦截乌克兰无人机与巡航导弹
专知会员服务
13+阅读 · 10月15日
《武器-目标分配问题:精确与近似求解算法》
专知会员服务
19+阅读 · 10月15日
相关资讯
【泡泡汇总】CVPR2019 SLAM Paperlist
泡泡机器人SLAM
14+阅读 · 2019年6月12日
Transferring Knowledge across Learning Processes
CreateAMind
29+阅读 · 2019年5月18日
逆强化学习-学习人先验的动机
CreateAMind
16+阅读 · 2019年1月18日
【泡泡一分钟】基于运动估计的激光雷达和相机标定方法
泡泡机器人SLAM
25+阅读 · 2019年1月17日
【推荐】深度学习目标检测概览
机器学习研究会
10+阅读 · 2017年9月1日
相关基金
国家自然科学基金
3+阅读 · 2015年12月31日
国家自然科学基金
0+阅读 · 2013年12月31日
国家自然科学基金
3+阅读 · 2013年12月31日
国家自然科学基金
1+阅读 · 2012年12月31日
国家自然科学基金
0+阅读 · 2011年12月31日
国家自然科学基金
0+阅读 · 2011年12月31日
国家自然科学基金
0+阅读 · 2011年12月31日
国家自然科学基金
0+阅读 · 2009年12月31日
Top
微信扫码咨询专知VIP会员