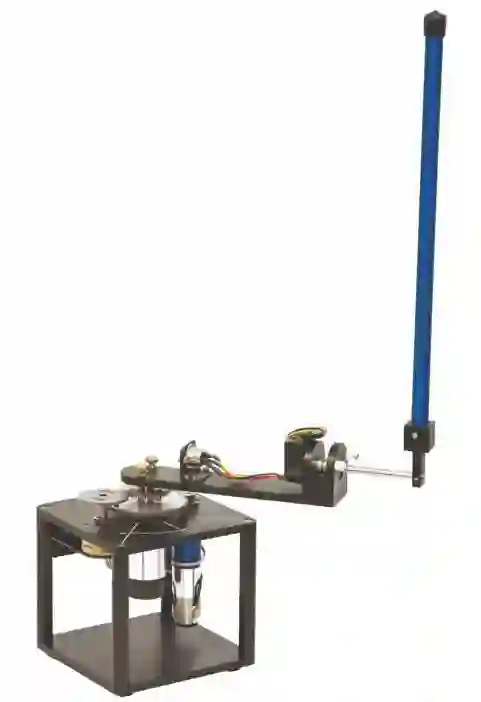
External and internal convertible (EIC) form-based motion control (i.e., EIC-based control) is one of the effective approaches for underactuated balance robots. By sequentially controller design, trajectory tracking of the actuated subsystem and balance of the unactuated subsystem can be achieved simultaneously. However, with certain conditions, there exists uncontrolled robot motion under the EIC-based control. We first identify these conditions and then propose an enhanced EIC-based control with a Gaussian process data-driven robot dynamic model. Under the new enhanced EIC-based control, the stability and performance of the closed-loop system is guaranteed. We demonstrate the GP-enhanced EIC-based control experimentally using two examples of underactuated balance robots.


翻译:外部和内部可转换(EIC)形式的运动控制(即基于EIC的控制)是欠驱动平衡机器人的有效方法之一。通过顺序控制器设计,可以实现驱动子系统的轨迹跟踪与非驱动子系统的平衡稳定。然而,在某些条件下,基于EIC的控制会导致机器人出现不可控运动。我们首先识别了这些条件,然后提出了一种基于高斯过程数据驱动机器人动力学模型的增强型EIC控制方法。在新的增强型EIC控制下,闭环系统的稳定性和性能得到了保证。我们通过两个欠驱动平衡机器人的实例,实验验证了高斯过程增强型EIC控制的效果。
0
下载
关闭预览

相关内容

FlowQA: Grasping Flow in History for Conversational Machine Comprehension
专知会员服务
35+阅读 · 2019年10月18日
Stabilizing Transformers for Reinforcement Learning
专知会员服务
61+阅读 · 2019年10月17日
《DeepGCNs: Making GCNs Go as Deep as CNNs》
专知会员服务
32+阅读 · 2019年10月17日
Keras François Chollet 《Deep Learning with Python 》, 386页pdf
专知会员服务
164+阅读 · 2019年10月12日
【SIGGRAPH2019】TensorFlow 2.0深度学习计算机图形学应用
专知会员服务
41+阅读 · 2019年10月9日
Hierarchically Structured Meta-learning
CreateAMind
27+阅读 · 2019年5月22日
Transferring Knowledge across Learning Processes
CreateAMind
29+阅读 · 2019年5月18日
强化学习的Unsupervised Meta-Learning
CreateAMind
18+阅读 · 2019年1月7日
Unsupervised Learning via Meta-Learning
CreateAMind
44+阅读 · 2019年1月3日
A Technical Overview of AI & ML in 2018 & Trends for 2019
待字闺中
18+阅读 · 2018年12月24日
disentangled-representation-papers
CreateAMind
26+阅读 · 2018年9月12日
STRCF for Visual Object Tracking
统计学习与视觉计算组
15+阅读 · 2018年5月29日
Focal Loss for Dense Object Detection
统计学习与视觉计算组
12+阅读 · 2018年3月15日
IJCAI | Cascade Dynamics Modeling with Attention-based RNN
KingsGarden
13+阅读 · 2017年7月16日
From Softmax to Sparsemax-ICML16(1)
KingsGarden
74+阅读 · 2016年11月26日
国家自然科学基金
2+阅读 · 2017年12月31日
国家自然科学基金
13+阅读 · 2017年12月31日
国家自然科学基金
2+阅读 · 2015年12月31日
国家自然科学基金
0+阅读 · 2015年12月31日
国家自然科学基金
47+阅读 · 2015年12月31日
国家自然科学基金
2+阅读 · 2015年12月31日
国家自然科学基金
0+阅读 · 2014年12月31日
国家自然科学基金
0+阅读 · 2014年12月31日
国家自然科学基金
0+阅读 · 2014年12月31日
国家自然科学基金
6+阅读 · 2014年12月31日
VIP会员
最新内容
俄罗斯如何拦截乌克兰无人机与巡航导弹
专知会员服务
9+阅读 · 10月15日
《武器-目标分配问题:精确与近似求解算法》
专知会员服务
14+阅读 · 10月15日
综述|谁来改进机器人?迈向物理递归自我改进
专知会员服务
10+阅读 · 10月14日
软件定义无人机蜂群给防空带来全新压力
专知会员服务
10+阅读 · 10月13日
《半自主无人地面战车的互操作性》66页
专知会员服务
14+阅读 · 10月13日
相关资讯
Hierarchically Structured Meta-learning
CreateAMind
27+阅读 · 2019年5月22日
Transferring Knowledge across Learning Processes
CreateAMind
29+阅读 · 2019年5月18日
强化学习的Unsupervised Meta-Learning
CreateAMind
18+阅读 · 2019年1月7日
Unsupervised Learning via Meta-Learning
CreateAMind
44+阅读 · 2019年1月3日
A Technical Overview of AI & ML in 2018 & Trends for 2019
待字闺中
18+阅读 · 2018年12月24日
disentangled-representation-papers
CreateAMind
26+阅读 · 2018年9月12日
STRCF for Visual Object Tracking
统计学习与视觉计算组
15+阅读 · 2018年5月29日
Focal Loss for Dense Object Detection
统计学习与视觉计算组
12+阅读 · 2018年3月15日
IJCAI | Cascade Dynamics Modeling with Attention-based RNN
KingsGarden
13+阅读 · 2017年7月16日
From Softmax to Sparsemax-ICML16(1)
KingsGarden
74+阅读 · 2016年11月26日
相关基金
国家自然科学基金
2+阅读 · 2017年12月31日
国家自然科学基金
13+阅读 · 2017年12月31日
国家自然科学基金
2+阅读 · 2015年12月31日
国家自然科学基金
0+阅读 · 2015年12月31日
国家自然科学基金
47+阅读 · 2015年12月31日
国家自然科学基金
2+阅读 · 2015年12月31日
国家自然科学基金
0+阅读 · 2014年12月31日
国家自然科学基金
0+阅读 · 2014年12月31日
国家自然科学基金
0+阅读 · 2014年12月31日
国家自然科学基金
6+阅读 · 2014年12月31日
Top
微信扫码咨询专知VIP会员