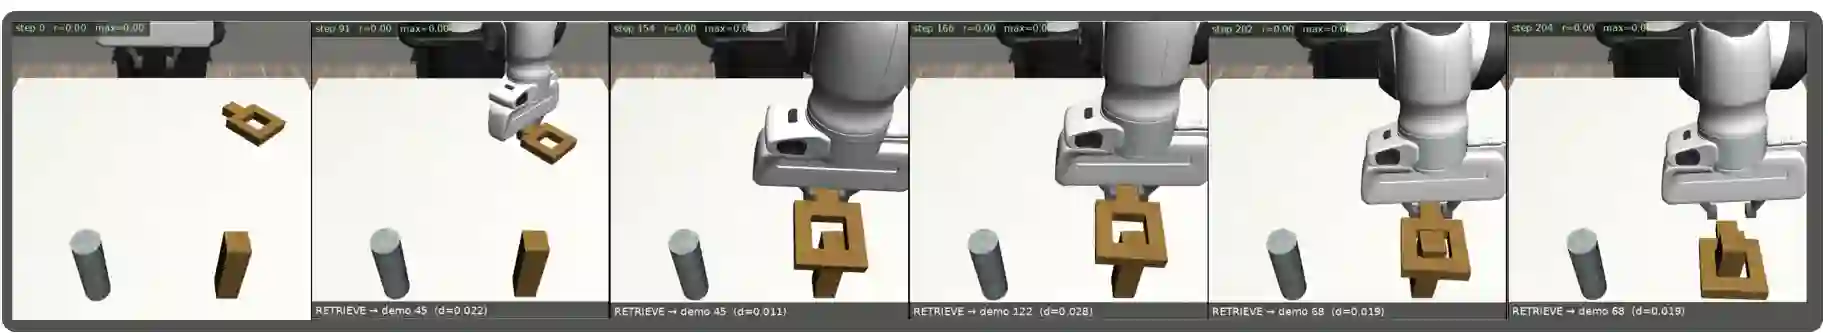
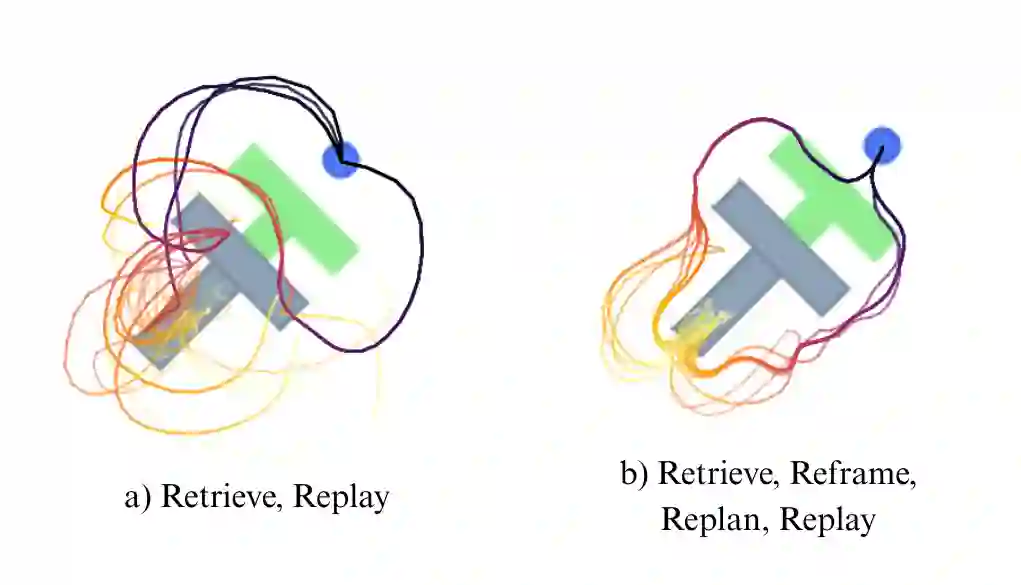
Object interaction tasks have been a focus of advances in imitation learning. End-to-end methods, dominated by diffusion and flow-based variants have shown leaps in performance while sacrificing interpretability. Object-centric and pose-informed variants have had a role in learning from demonstration in manipulation tasks. In this paper, we revisit a few modern imitation learning benchmarks for object interactions, with the aim of composing a framework that repurposes principled theories of manipulation, preserving both performance and interpretability. For image observations, lightweight training is proposed for model-free pose estimation of the target object, using self-supervision over the demonstration data available for imitation learning. This information is then used to inform a manipulation mode-aware retrieval of a demonstration, a mode-aware transformation, a replan step that connects to the retrieval point while preserving mode constraints, and finally rolling out the transformed demonstration. These compose four key steps of the proposed RE4 framework, evaluated over state-based and image-based benchmarks in Push-T and Robomimic. An adversarial benchmark that evaluates sparse data regions of image-based Push-T showcases the robustness, further bolstered by indications from low-data regime experiments. The current work shows promise in using simple interpretable building blocks to learn manipulation skills.


翻译:暂无翻译
0
下载
关闭预览

相关内容

最新《Transformers模型》教程,64页ppt
专知会员服务
326+阅读 · 2020年11月26日
Stabilizing Transformers for Reinforcement Learning
专知会员服务
61+阅读 · 2019年10月17日
Hierarchically Structured Meta-learning
CreateAMind
27+阅读 · 2019年5月22日
Transferring Knowledge across Learning Processes
CreateAMind
29+阅读 · 2019年5月18日
强化学习的Unsupervised Meta-Learning
CreateAMind
18+阅读 · 2019年1月7日
Unsupervised Learning via Meta-Learning
CreateAMind
44+阅读 · 2019年1月3日
A Technical Overview of AI & ML in 2018 & Trends for 2019
待字闺中
18+阅读 · 2018年12月24日
Relation Networks for Object Detection 论文笔记
统计学习与视觉计算组
16+阅读 · 2018年4月18日
国家自然科学基金
6+阅读 · 2017年12月31日
国家自然科学基金
20+阅读 · 2015年12月31日
国家自然科学基金
0+阅读 · 2015年12月31日
国家自然科学基金
1+阅读 · 2015年12月31日
国家自然科学基金
3+阅读 · 2015年12月31日
国家自然科学基金
2+阅读 · 2015年12月31日
国家自然科学基金
0+阅读 · 2014年12月31日
国家自然科学基金
0+阅读 · 2014年12月31日
国家自然科学基金
0+阅读 · 2014年12月31日
Arxiv
15+阅读 · 2022年6月14日
Arxiv
20+阅读 · 2021年9月21日
VIP会员
最新内容
《美空军2026条令文件:对海压制作战》
专知会员服务
23+阅读 · 11月9日
人工智能与战争的未来
专知会员服务
10+阅读 · 11月8日
《Agent Mosaic:识别智能体LLM系统中的机密泄露》
专知会员服务
10+阅读 · 11月8日
人工智能在军事教育中的应用:若干视角与经验
专知会员服务
11+阅读 · 11月6日
“星链”减速与不断适应的乌克兰
专知会员服务
9+阅读 · 11月6日
美国中期选举之后:帕兰提尔面临不确定性?
专知会员服务
6+阅读 · 11月6日
相关VIP内容
最新《Transformers模型》教程,64页ppt
专知会员服务
326+阅读 · 2020年11月26日
Stabilizing Transformers for Reinforcement Learning
专知会员服务
61+阅读 · 2019年10月17日
相关资讯
相关基金
国家自然科学基金
6+阅读 · 2017年12月31日
国家自然科学基金
20+阅读 · 2015年12月31日
国家自然科学基金
0+阅读 · 2015年12月31日
国家自然科学基金
1+阅读 · 2015年12月31日
国家自然科学基金
3+阅读 · 2015年12月31日
国家自然科学基金
2+阅读 · 2015年12月31日
国家自然科学基金
0+阅读 · 2014年12月31日
国家自然科学基金
0+阅读 · 2014年12月31日
国家自然科学基金
0+阅读 · 2014年12月31日
Top
微信扫码咨询专知VIP会员