

Swarm robots have attracted growing interest as a physical interface for human--computer interaction, since a swarm can reshape its formation to fit the objects and surroundings it works with. For a human operator, however, adapting the swarm's behavior remains difficult. Most existing methods require the user to specify where the swarm should go, and they offer no intuitive way to change the collective's behavior as each task demands. We present Fluidic Body, a system that lets a person operate a swarm of fluid-imitating robots as an extension of the hand. The system places a virtual fluid between the hand and the swarm, and the user adapts the swarm's behavior to each task by changing the fluid's properties through simple hand movements. When the user opens the hand, the swarm becomes soft enough to deform and flow around obstacles. Closing the hand turns it into a hard, cohesive body that can push objects. We evaluated the controller's performance and its operability in two simulation experiments and one demonstration with physical robots. First, our controller handled both obstacle avoidance and object transportation better than an existing method that behaves the same way in every task. Second, in a VR user study, 17 participants completed the combined avoidance-and-transportation task faster and more reliably than with that method. They also reported a lower workload and a stronger sense of agency. Finally, this experience carried over to physical robots in a real-world demonstration (88 participants). These results suggest that treating a swarm as a fluid, a material people already understand, allows a robot swarm to work as a deformable extension of the human body.
翻译:暂无翻译


相关内容
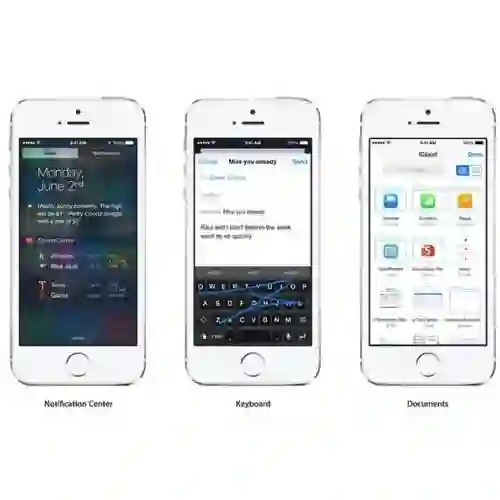
- Today (iOS and OS X): widgets for the Today view of Notification Center
- Share (iOS and OS X): post content to web services or share content with others
- Actions (iOS and OS X): app extensions to view or manipulate inside another app
- Photo Editing (iOS): edit a photo or video in Apple's Photos app with extensions from a third-party apps
- Finder Sync (OS X): remote file storage in the Finder with support for Finder content annotation
- Storage Provider (iOS): an interface between files inside an app and other apps on a user's device
- Custom Keyboard (iOS): system-wide alternative keyboards
Source: iOS 8 Extensions: Apple’s Plan for a Powerful App Ecosystem




 微信扫码咨询专知VIP会员