

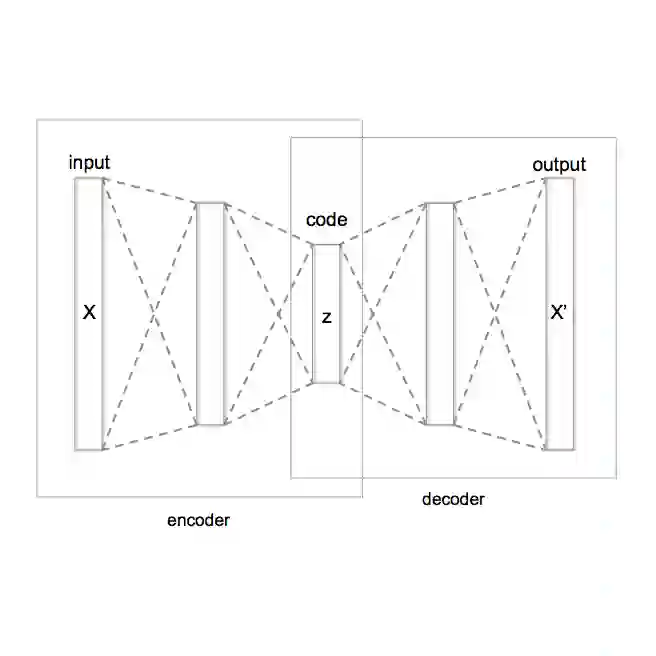
Vision-based autonomous navigation for low-cost robots remains a fundamental challenge, primarily due to the significant gap between simulated training environments and real-world operational conditions. Direct policy transfer from simulation is often ineffective, while training exclusively on real data is impractical. We propose a hybrid transfer learning framework that effectively bridges the sim-to-real gap by combining domain randomization with feature-level domain adaptation. Our method employs a dual convolutional variational autoencoder architecture with a shared decoder, trained on an extensive set of 45225 simulated images and a minimal set of only 4556 real-world samples. This architecture learns a compact, common latent representation space that aligns the distributions of both domains. The adaptation process is further enhanced by two complementary data augmentation techniques designed to expand the limited real-world data. Experimental evaluation demonstrates that our method achieves an average success rate of almost 91% on image classification tasks for real-world indoor navigation, significantly outperforming both simulation-only and real-world-only training. We validate these findings through a direct, real-world deployment, where the proposed policy successfully guides a low-cost robot in a reactive exploration task. Furthermore, we validate the model's efficiency through a rigorous computational estimation, confirming its suitability for resource-constrained embedded platforms such as the Raspberry Pi 4 and NVIDIA Jetson Nano. This work presents a practical solution for developing effective and efficient navigation policies for low-cost robotic systems.
翻译:暂无翻译


相关内容



 微信扫码咨询专知VIP会员