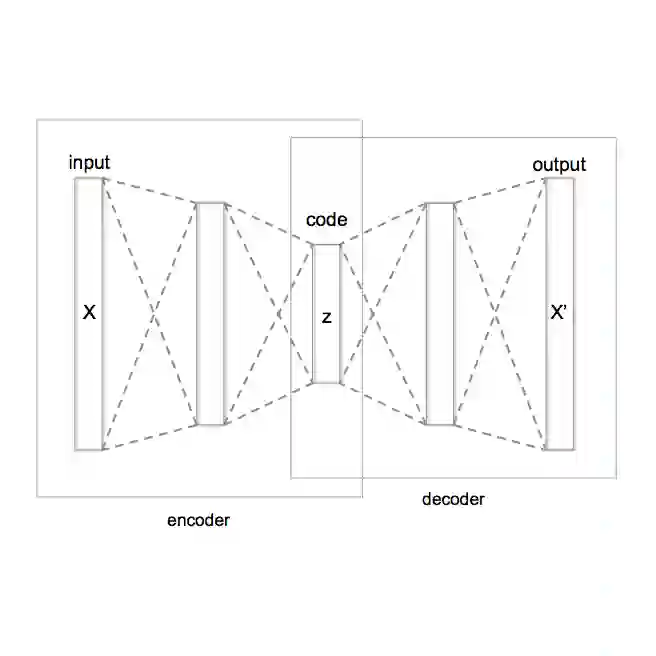
We propose an efficient retraining strategy for a parameterized Reduced Order Model (ROM) that attains accuracy comparable to full retraining while requiring only a fraction of the computational time and relying solely on sparse observations of the full system. The architecture employs an encode-process-decode structure: a Variational Autoencoder (VAE) to perform dimensionality reduction, and a transformer network to evolve the latent states and model the dynamics. The ROM is parameterized by an external control variable, the Reynolds number in the Navier-Stokes setting, with the transformer exploiting attention mechanisms to capture both temporal dependencies and parameter effects. The probabilistic VAE enables stochastic sampling of trajectory ensembles, providing predictive means and uncertainty quantification through the first two moments. After initial training on a limited set of dynamical regimes, the model is adapted to out-of-sample parameter regions using only sparse data. Its probabilistic formulation naturally supports ensemble generation, which we employ within an ensemble Kalman filtering framework to assimilate data and reconstruct full-state trajectories from minimal observations. We further show that, for the dynamical system considered, the dominant source of error in out-of-sample forecasts stems from distortions of the latent manifold rather than changes in the latent dynamics. Consequently, retraining can be limited to the autoencoder, allowing for a lightweight, computationally efficient, real-time adaptation procedure with very sparse fine-tuning data.


翻译:暂无翻译

0
下载
关闭预览

相关内容

ACM/IEEE第23届模型驱动工程语言和系统国际会议,是模型驱动软件和系统工程的首要会议系列,由ACM-SIGSOFT和IEEE-TCSE支持组织。自1998年以来,模型涵盖了建模的各个方面,从语言和方法到工具和应用程序。模特的参加者来自不同的背景,包括研究人员、学者、工程师和工业专业人士。MODELS 2019是一个论坛,参与者可以围绕建模和模型驱动的软件和系统交流前沿研究成果和创新实践经验。今年的版本将为建模社区提供进一步推进建模基础的机会,并在网络物理系统、嵌入式系统、社会技术系统、云计算、大数据、机器学习、安全、开源等新兴领域提出建模的创新应用以及可持续性。 官网链接:http://www.modelsconference.org/
FlowQA: Grasping Flow in History for Conversational Machine Comprehension
专知会员服务
35+阅读 · 2019年10月18日
Stabilizing Transformers for Reinforcement Learning
专知会员服务
61+阅读 · 2019年10月17日
【泡泡点云时空】基于分割方法的物体六维姿态估计
泡泡机器人SLAM
18+阅读 · 2019年9月15日
【泡泡图灵智库】基于CPU的实时6D物体姿态估计(arXiv)
泡泡机器人SLAM
12+阅读 · 2019年1月26日
meta learning 17年:MAML SNAIL
CreateAMind
11+阅读 · 2019年1月2日
用 LDA 和 LSA 两种方法来降维和做 Topic 建模
AI研习社
13+阅读 · 2018年8月24日
IJCAI | Cascade Dynamics Modeling with Attention-based RNN
KingsGarden
13+阅读 · 2017年7月16日
国家自然科学基金
0+阅读 · 2015年12月31日
国家自然科学基金
1+阅读 · 2015年12月31日
国家自然科学基金
7+阅读 · 2015年12月31日
国家自然科学基金
0+阅读 · 2015年12月31日
国家自然科学基金
0+阅读 · 2015年12月31日
国家自然科学基金
0+阅读 · 2015年12月31日
国家自然科学基金
0+阅读 · 2014年12月31日
国家自然科学基金
1+阅读 · 2014年12月31日
国家自然科学基金
16+阅读 · 2013年12月31日
VIP会员
最新内容
世界模型入门:从序贯决策到通用智能体
专知会员服务
4+阅读 · 10月24日
军事域更好使用人工智能的实用指南
专知会员服务
9+阅读 · 10月22日
《衡量语言模型中的作战规划能力》
专知会员服务
14+阅读 · 10月20日
Maven智能系统:帕兰提尔军事人工智能平台详解
专知会员服务
16+阅读 · 10月20日
《测试自动化框架在敏捷软件开发中的角色》
专知会员服务
8+阅读 · 10月20日
俄罗斯如何拦截乌克兰无人机与巡航导弹
专知会员服务
12+阅读 · 10月15日
《武器-目标分配问题:精确与近似求解算法》
专知会员服务
17+阅读 · 10月15日
相关VIP内容
FlowQA: Grasping Flow in History for Conversational Machine Comprehension
专知会员服务
35+阅读 · 2019年10月18日
Stabilizing Transformers for Reinforcement Learning
专知会员服务
61+阅读 · 2019年10月17日
相关基金
国家自然科学基金
0+阅读 · 2015年12月31日
国家自然科学基金
1+阅读 · 2015年12月31日
国家自然科学基金
7+阅读 · 2015年12月31日
国家自然科学基金
0+阅读 · 2015年12月31日
国家自然科学基金
0+阅读 · 2015年12月31日
国家自然科学基金
0+阅读 · 2015年12月31日
国家自然科学基金
0+阅读 · 2014年12月31日
国家自然科学基金
1+阅读 · 2014年12月31日
国家自然科学基金
16+阅读 · 2013年12月31日
Top
微信扫码咨询专知VIP会员