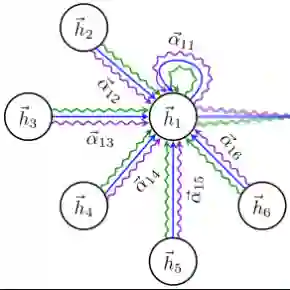
Timely road-network map updates are essential to navigation and autonomous driving. Three key tasks are intra-intersection road network generation, merging/diverging detection, and drivable-area detection, covering topology, geometry, and attributes, respectively. Separate pipelines duplicate rule maintenance, quality assurance, and manual verification, increasing operational costs. We propose PGU-Decoder, a production-grade unified decoding framework for semantic prediction across these tasks. A Prior Query Module (PQM) constructs point-level prior queries from sampled locations on road-network geometries. Fixed reference points preserve positional priors throughout decoding, allowing the model to focus on surrounding context. Point-level representations are aggregated into instance-level representations, and a Relational Graph Attention Network (RGAT) captures inter-instance dependencies. Task-specific heads then generate predictions. We validate PGU-Decoder in large-scale automated road-network map updating across more than 360 cities in China, where it consistently outperforms seven baselines. Following deployment at AutoNavi Map, it achieves quality scores above 98% on all three tasks, reduces manual verification costs by 95%, and increases update frequency from weekly to hourly. These results demonstrate a practical and cost-effective industrial solution for road-network map updating.


翻译:暂无翻译

0
下载
关闭预览

相关内容

【PKDD 2021】PaGNN:基于交互结构学习的链路预测
专知会员服务
18+阅读 · 2021年11月26日
【AAAI2021】Graph Diffusion Network提升交通流量预测精度
专知会员服务
54+阅读 · 2021年1月21日
【GNN】图神经网络入门之GRN图循环网络
深度学习自然语言处理
17+阅读 · 2020年5月9日
图机器学习 2.2-2.4 Properties of Networks, Random Graph
图与推荐
10+阅读 · 2020年3月28日
我国智能网联汽车车路协同发展路线政策及示范环境研究
Network Embedding 指南
专知
22+阅读 · 2018年8月13日
智慧公路建设方案
智能交通技术
30+阅读 · 2018年2月28日
国家自然科学基金
0+阅读 · 2017年12月31日
国家自然科学基金
0+阅读 · 2015年12月31日
国家自然科学基金
0+阅读 · 2015年12月31日
国家自然科学基金
4+阅读 · 2015年12月31日
国家自然科学基金
0+阅读 · 2015年12月31日
国家自然科学基金
0+阅读 · 2014年12月31日
国家自然科学基金
0+阅读 · 2014年12月31日
国家自然科学基金
1+阅读 · 2014年12月31日
国家自然科学基金
2+阅读 · 2014年12月31日
Arxiv
26+阅读 · 2018年2月27日
VIP会员
最新内容
乌克兰无人机饱和战场中的错误教训
专知会员服务
17+阅读 · 11月17日
面向最后一战术英里:美军无人机创新尝试
专知会员服务
14+阅读 · 11月17日
《美空军2026条令文件:对海压制作战》
专知会员服务
30+阅读 · 11月9日
人工智能与战争的未来
专知会员服务
14+阅读 · 11月8日
《Agent Mosaic:识别智能体LLM系统中的机密泄露》
专知会员服务
14+阅读 · 11月8日
相关VIP内容
【PKDD 2021】PaGNN:基于交互结构学习的链路预测
专知会员服务
18+阅读 · 2021年11月26日
【AAAI2021】Graph Diffusion Network提升交通流量预测精度
专知会员服务
54+阅读 · 2021年1月21日
相关资讯
【GNN】图神经网络入门之GRN图循环网络
深度学习自然语言处理
17+阅读 · 2020年5月9日
图机器学习 2.2-2.4 Properties of Networks, Random Graph
图与推荐
10+阅读 · 2020年3月28日
我国智能网联汽车车路协同发展路线政策及示范环境研究
Network Embedding 指南
专知
22+阅读 · 2018年8月13日
智慧公路建设方案
智能交通技术
30+阅读 · 2018年2月28日
相关基金
国家自然科学基金
0+阅读 · 2017年12月31日
国家自然科学基金
0+阅读 · 2015年12月31日
国家自然科学基金
0+阅读 · 2015年12月31日
国家自然科学基金
4+阅读 · 2015年12月31日
国家自然科学基金
0+阅读 · 2015年12月31日
国家自然科学基金
0+阅读 · 2014年12月31日
国家自然科学基金
0+阅读 · 2014年12月31日
国家自然科学基金
1+阅读 · 2014年12月31日
国家自然科学基金
2+阅读 · 2014年12月31日
Top
微信扫码咨询专知VIP会员