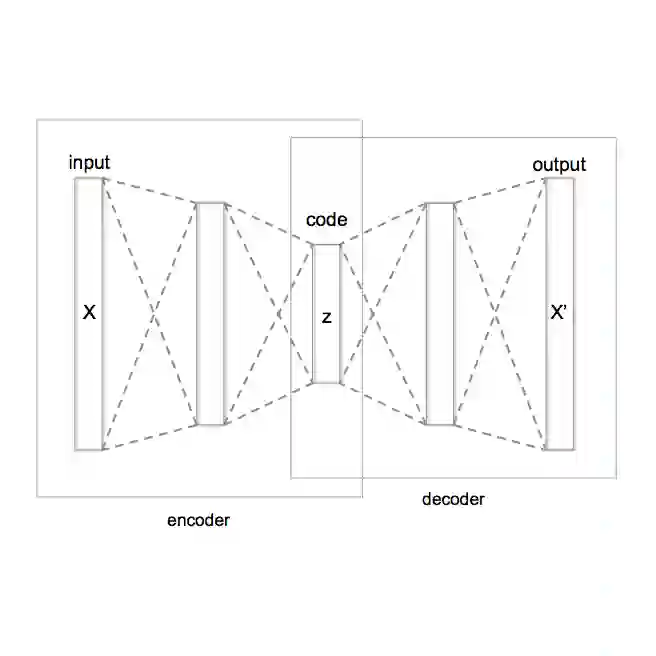
This work presents a mapless navigation approach for outdoor applications. It combines the exploratory capacity of conditional variational autoencoders (CVAEs) to generate trajectories and the semantic segmentation capabilities of a lightweight visual language model (VLM) to select the trajectory to execute. Open-vocabulary segmentation is used to score and select the generated trajectories based on natural language, and a state-of-the-art local planner executes velocity commands. One of the key features of the proposed approach is its ability to generate a large variability of trajectories and select them to navigate in real-time. In real-world outdoor experiments, Sem-NaVAE achieves a 90% success rate across routes of 120-240m in unseen environments, outperforming the nearest baseline by 10% while remaining within 7% of a map-based upper bound. A video showing an experimental run of the system can be found in https://youtu.be/i3R5ey5O2yk.


翻译:暂无翻译

0
下载
关闭预览

相关内容

《战场GPS拒止环境下基于地标定位的安全路径导航》
专知会员服务
20+阅读 · 2025年5月22日
CoRL 2024 | InstructNav:通用指令导航大模型系统
专知会员服务
24+阅读 · 2024年9月21日
RSS 2024 | NaVid:视觉语言导航大模型
专知会员服务
34+阅读 · 2024年6月9日
半监督多任务学习:Semisupervised Multitask Learning
我爱读PAMI
18+阅读 · 2018年4月29日
国家自然科学基金
0+阅读 · 2017年12月31日
国家自然科学基金
8+阅读 · 2015年12月31日
国家自然科学基金
0+阅读 · 2015年12月31日
国家自然科学基金
0+阅读 · 2015年12月31日
国家自然科学基金
0+阅读 · 2015年12月31日
国家自然科学基金
0+阅读 · 2014年12月31日
国家自然科学基金
3+阅读 · 2014年12月31日
国家自然科学基金
20+阅读 · 2011年12月31日
国家自然科学基金
24+阅读 · 2011年12月31日
Arxiv
0+阅读 · 5月20日
VIP会员
最新内容
《美空军2026条令文件:对海压制作战》
专知会员服务
25+阅读 · 11月9日
人工智能与战争的未来
专知会员服务
10+阅读 · 11月8日
《Agent Mosaic:识别智能体LLM系统中的机密泄露》
专知会员服务
12+阅读 · 11月8日
人工智能在军事教育中的应用:若干视角与经验
专知会员服务
12+阅读 · 11月6日
“星链”减速与不断适应的乌克兰
专知会员服务
10+阅读 · 11月6日
美国中期选举之后:帕兰提尔面临不确定性?
专知会员服务
7+阅读 · 11月6日
相关基金
国家自然科学基金
0+阅读 · 2017年12月31日
国家自然科学基金
8+阅读 · 2015年12月31日
国家自然科学基金
0+阅读 · 2015年12月31日
国家自然科学基金
0+阅读 · 2015年12月31日
国家自然科学基金
0+阅读 · 2015年12月31日
国家自然科学基金
0+阅读 · 2014年12月31日
国家自然科学基金
3+阅读 · 2014年12月31日
国家自然科学基金
20+阅读 · 2011年12月31日
国家自然科学基金
24+阅读 · 2011年12月31日
Top
微信扫码咨询专知VIP会员