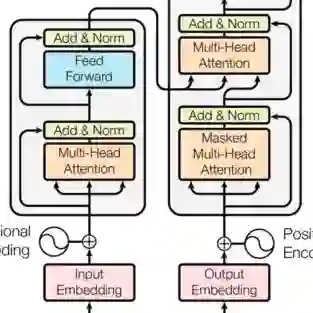
Transformer-based models have significantly advanced natural language processing and computer vision in recent years. However, due to the irregular and disordered structure of point cloud data, transformer-based models for 3D deep learning are still in their infancy compared to other methods. In this paper we present Point Cross-Attention Transformer (PointCAT), a novel end-to-end network architecture using cross-attentions mechanism for point cloud representing. Our approach combines multi-scale features via two seprate cross-attention transformer branches. To reduce the computational increase brought by multi-branch structure, we further introduce an efficient model for shape classification, which only process single class token of one branch as a query to calculate attention map with the other. Extensive experiments demonstrate that our method outperforms or achieves comparable performance to several approaches in shape classification, part segmentation and semantic segmentation tasks.


翻译:近年来,基于Transformer的模型显著推进了自然语言处理与计算机视觉领域的发展。然而,由于点云数据具有不规则和无序的结构特点,相比其他方法,基于Transformer的3D深度学习模型仍处于发展初期。本文提出点云交叉注意力Transformer(PointCAT),这是一种利用交叉注意力机制进行点云表示的新型端到端网络架构。该方法通过两个独立的交叉注意力Transformer分支融合多尺度特征。为降低多分支结构带来的计算量增长,我们进一步引入了一种高效的形状分类模型,该模型仅将一个分支中的单一类令牌作为查询,与另一分支计算注意力图。大量实验表明,在形状分类、部件分割和语义分割任务中,我们的方法优于或达到与多种方法相当的性能。

0
下载
关闭预览

相关内容

根据激光测量原理得到的点云,包括三维坐标(XYZ)和激光反射强度(Intensity)。 根据摄影测量原理得到的点云,包括三维坐标(XYZ)和颜色信息(RGB)。 结合激光测量和摄影测量原理得到点云,包括三维坐标(XYZ)、激光反射强度(Intensity)和颜色信息(RGB)。 在获取物体表面每个采样点的空间坐标后,得到的是一个点的集合,称之为“点云”(Point Cloud)
【ICLR 2019】双曲注意力网络,Hyperbolic  Attention Network
专知会员服务
84+阅读 · 2020年6月21日
专知会员服务
61+阅读 · 2020年3月19日
[综述]深度学习下的场景文本检测与识别
专知会员服务
78+阅读 · 2019年10月10日
【SIGGRAPH2019】TensorFlow 2.0深度学习计算机图形学应用
专知会员服务
41+阅读 · 2019年10月9日
Hierarchically Structured Meta-learning
CreateAMind
27+阅读 · 2019年5月22日
CVPR2019| 05-20更新17篇点云相关论文及代码合集
极市平台
23+阅读 · 2019年5月20日
国家自然科学基金
2+阅读 · 2015年12月31日
国家自然科学基金
0+阅读 · 2013年12月31日
国家自然科学基金
0+阅读 · 2013年12月31日
国家自然科学基金
0+阅读 · 2011年12月31日
国家自然科学基金
0+阅读 · 2009年12月31日
国家自然科学基金
1+阅读 · 2008年12月31日
国家自然科学基金
0+阅读 · 2008年12月31日
Self-Attention Graph Pooling
Arxiv
13+阅读 · 2019年6月13日
Arxiv
12+阅读 · 2019年1月24日
Arxiv
29+阅读 · 2017年12月6日
VIP会员
最新内容
乌克兰无人机饱和战场中的错误教训
专知会员服务
1+阅读 · 今天15:13
面向最后一战术英里:美军无人机创新尝试
专知会员服务
1+阅读 · 今天14:52
《美空军2026条令文件:对海压制作战》
专知会员服务
25+阅读 · 11月9日
人工智能与战争的未来
专知会员服务
10+阅读 · 11月8日
《Agent Mosaic:识别智能体LLM系统中的机密泄露》
专知会员服务
12+阅读 · 11月8日
人工智能在军事教育中的应用:若干视角与经验
专知会员服务
13+阅读 · 11月6日
“星链”减速与不断适应的乌克兰
专知会员服务
10+阅读 · 11月6日
美国中期选举之后:帕兰提尔面临不确定性?
专知会员服务
7+阅读 · 11月6日
相关VIP内容
【ICLR 2019】双曲注意力网络,Hyperbolic  Attention Network
专知会员服务
84+阅读 · 2020年6月21日
专知会员服务
61+阅读 · 2020年3月19日
[综述]深度学习下的场景文本检测与识别
专知会员服务
78+阅读 · 2019年10月10日
【SIGGRAPH2019】TensorFlow 2.0深度学习计算机图形学应用
专知会员服务
41+阅读 · 2019年10月9日
相关资讯
Hierarchically Structured Meta-learning
CreateAMind
27+阅读 · 2019年5月22日
CVPR2019| 05-20更新17篇点云相关论文及代码合集
极市平台
23+阅读 · 2019年5月20日
相关基金
国家自然科学基金
2+阅读 · 2015年12月31日
国家自然科学基金
0+阅读 · 2013年12月31日
国家自然科学基金
0+阅读 · 2013年12月31日
国家自然科学基金
0+阅读 · 2011年12月31日
国家自然科学基金
0+阅读 · 2009年12月31日
国家自然科学基金
1+阅读 · 2008年12月31日
国家自然科学基金
0+阅读 · 2008年12月31日
Top
微信扫码咨询专知VIP会员