

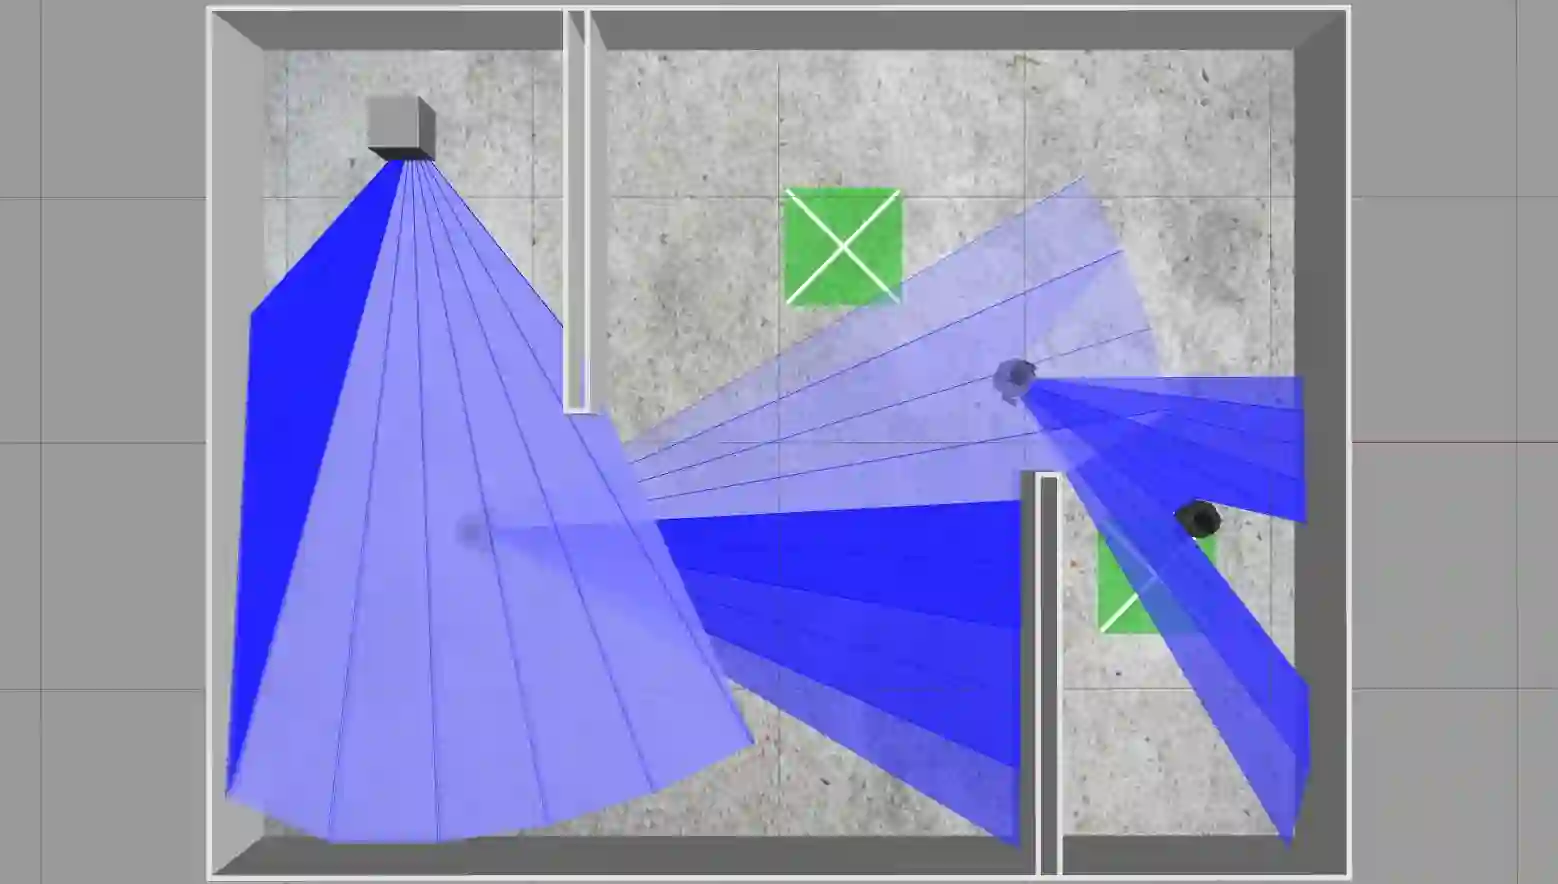
This work addresses the problem of motion planning for a group of nonholonomic robots under Visible Light Communication (VLC) connectivity requirements. In particular, we consider an inspection task performed by a Robot Chain Control System (RCCS), where a leader must visit relevant regions of an environment while the remaining robots operate as relays, maintaining the connectivity between the leader and a base station. We leverage Mixed-Integer Linear Programming (MILP) to design a trajectory planner that can coordinate the RCCS, minimizing time and control effort while also handling the issues of directed Line-Of-Sight (LOS), connectivity over directed networks, and the nonlinearity of the robots' dynamics. The efficacy of the proposal is demonstrated with realistic simulations in the Gazebo environment using the Turtlebot3 robot platform.


翻译:本文研究了在可见光通信(VLC)连通性需求下一组非完整机器人的运动规划问题。具体而言,我们考虑由机器人链控制系统(RCCS)执行的巡检任务:其中领航机器人必须访问环境中的关键区域,而其余机器人作为中继节点运行,以维持领航机器人与基站之间的连通性。我们利用混合整数线性规划(MILP)设计了一种轨迹规划器,能够协调RCCS的运行,在最小化时间和控制代价的同时,处理有向视距(LOS)、有向网络连通性以及机器人动力学非线性等难题。通过在Gazebo仿真环境中使用Turtlebot3机器人平台进行的真实场景仿真,验证了所提方案的有效性。

0
下载
关闭预览

相关内容

机器人(英语:Robot)包括一切模拟人类行为或思想与模拟其他生物的机械(如机器狗,机器猫等)。狭义上对机器人的定义还有很多分类法及争议,有些电脑程序甚至也被称为机器人。在当代工业中,机器人指能自动运行任务的人造机器设备,用以取代或协助人类工作,一般会是机电设备,由计算机程序或是电子电路控制。

知识荟萃

精品入门和进阶教程、论文和代码整理等

更多

查看相关VIP内容、论文、资讯等
FlowQA: Grasping Flow in History for Conversational Machine Comprehension
专知会员服务
35+阅读 · 2019年10月18日
Stabilizing Transformers for Reinforcement Learning
专知会员服务
61+阅读 · 2019年10月17日
《DeepGCNs: Making GCNs Go as Deep as CNNs》
专知会员服务
32+阅读 · 2019年10月17日
Keras François Chollet 《Deep Learning with Python 》, 386页pdf
专知会员服务
164+阅读 · 2019年10月12日
Hierarchically Structured Meta-learning
CreateAMind
27+阅读 · 2019年5月22日
Transferring Knowledge across Learning Processes
CreateAMind
29+阅读 · 2019年5月18日
强化学习的Unsupervised Meta-Learning
CreateAMind
18+阅读 · 2019年1月7日
Unsupervised Learning via Meta-Learning
CreateAMind
44+阅读 · 2019年1月3日
A Technical Overview of AI & ML in 2018 & Trends for 2019
待字闺中
18+阅读 · 2018年12月24日
STRCF for Visual Object Tracking
统计学习与视觉计算组
15+阅读 · 2018年5月29日
Focal Loss for Dense Object Detection
统计学习与视觉计算组
12+阅读 · 2018年3月15日
论文浅尝 | Question Answering over Freebase
开放知识图谱
19+阅读 · 2018年1月9日
IJCAI | Cascade Dynamics Modeling with Attention-based RNN
KingsGarden
13+阅读 · 2017年7月16日
From Softmax to Sparsemax-ICML16(1)
KingsGarden
74+阅读 · 2016年11月26日
国家自然科学基金
13+阅读 · 2017年12月31日
国家自然科学基金
2+阅读 · 2015年12月31日
国家自然科学基金
3+阅读 · 2015年12月31日
国家自然科学基金
1+阅读 · 2015年12月31日
国家自然科学基金
47+阅读 · 2015年12月31日
国家自然科学基金
2+阅读 · 2015年12月31日
国家自然科学基金
0+阅读 · 2014年12月31日
国家自然科学基金
0+阅读 · 2014年12月31日
国家自然科学基金
2+阅读 · 2014年12月31日
VIP会员
最新内容
世界模型入门:从序贯决策到通用智能体
专知会员服务
4+阅读 · 10月24日
军事域更好使用人工智能的实用指南
专知会员服务
9+阅读 · 10月22日
《衡量语言模型中的作战规划能力》
专知会员服务
14+阅读 · 10月20日
Maven智能系统:帕兰提尔军事人工智能平台详解
专知会员服务
16+阅读 · 10月20日
《测试自动化框架在敏捷软件开发中的角色》
专知会员服务
8+阅读 · 10月20日
俄罗斯如何拦截乌克兰无人机与巡航导弹
专知会员服务
12+阅读 · 10月15日
《武器-目标分配问题:精确与近似求解算法》
专知会员服务
17+阅读 · 10月15日
相关VIP内容
相关资讯
Hierarchically Structured Meta-learning
CreateAMind
27+阅读 · 2019年5月22日
Transferring Knowledge across Learning Processes
CreateAMind
29+阅读 · 2019年5月18日
强化学习的Unsupervised Meta-Learning
CreateAMind
18+阅读 · 2019年1月7日
Unsupervised Learning via Meta-Learning
CreateAMind
44+阅读 · 2019年1月3日
A Technical Overview of AI & ML in 2018 & Trends for 2019
待字闺中
18+阅读 · 2018年12月24日
STRCF for Visual Object Tracking
统计学习与视觉计算组
15+阅读 · 2018年5月29日
Focal Loss for Dense Object Detection
统计学习与视觉计算组
12+阅读 · 2018年3月15日
论文浅尝 | Question Answering over Freebase
开放知识图谱
19+阅读 · 2018年1月9日
IJCAI | Cascade Dynamics Modeling with Attention-based RNN
KingsGarden
13+阅读 · 2017年7月16日
From Softmax to Sparsemax-ICML16(1)
KingsGarden
74+阅读 · 2016年11月26日
相关基金
国家自然科学基金
13+阅读 · 2017年12月31日
国家自然科学基金
2+阅读 · 2015年12月31日
国家自然科学基金
3+阅读 · 2015年12月31日
国家自然科学基金
1+阅读 · 2015年12月31日
国家自然科学基金
47+阅读 · 2015年12月31日
国家自然科学基金
2+阅读 · 2015年12月31日
国家自然科学基金
0+阅读 · 2014年12月31日
国家自然科学基金
0+阅读 · 2014年12月31日
国家自然科学基金
2+阅读 · 2014年12月31日
Top
微信扫码咨询专知VIP会员



