

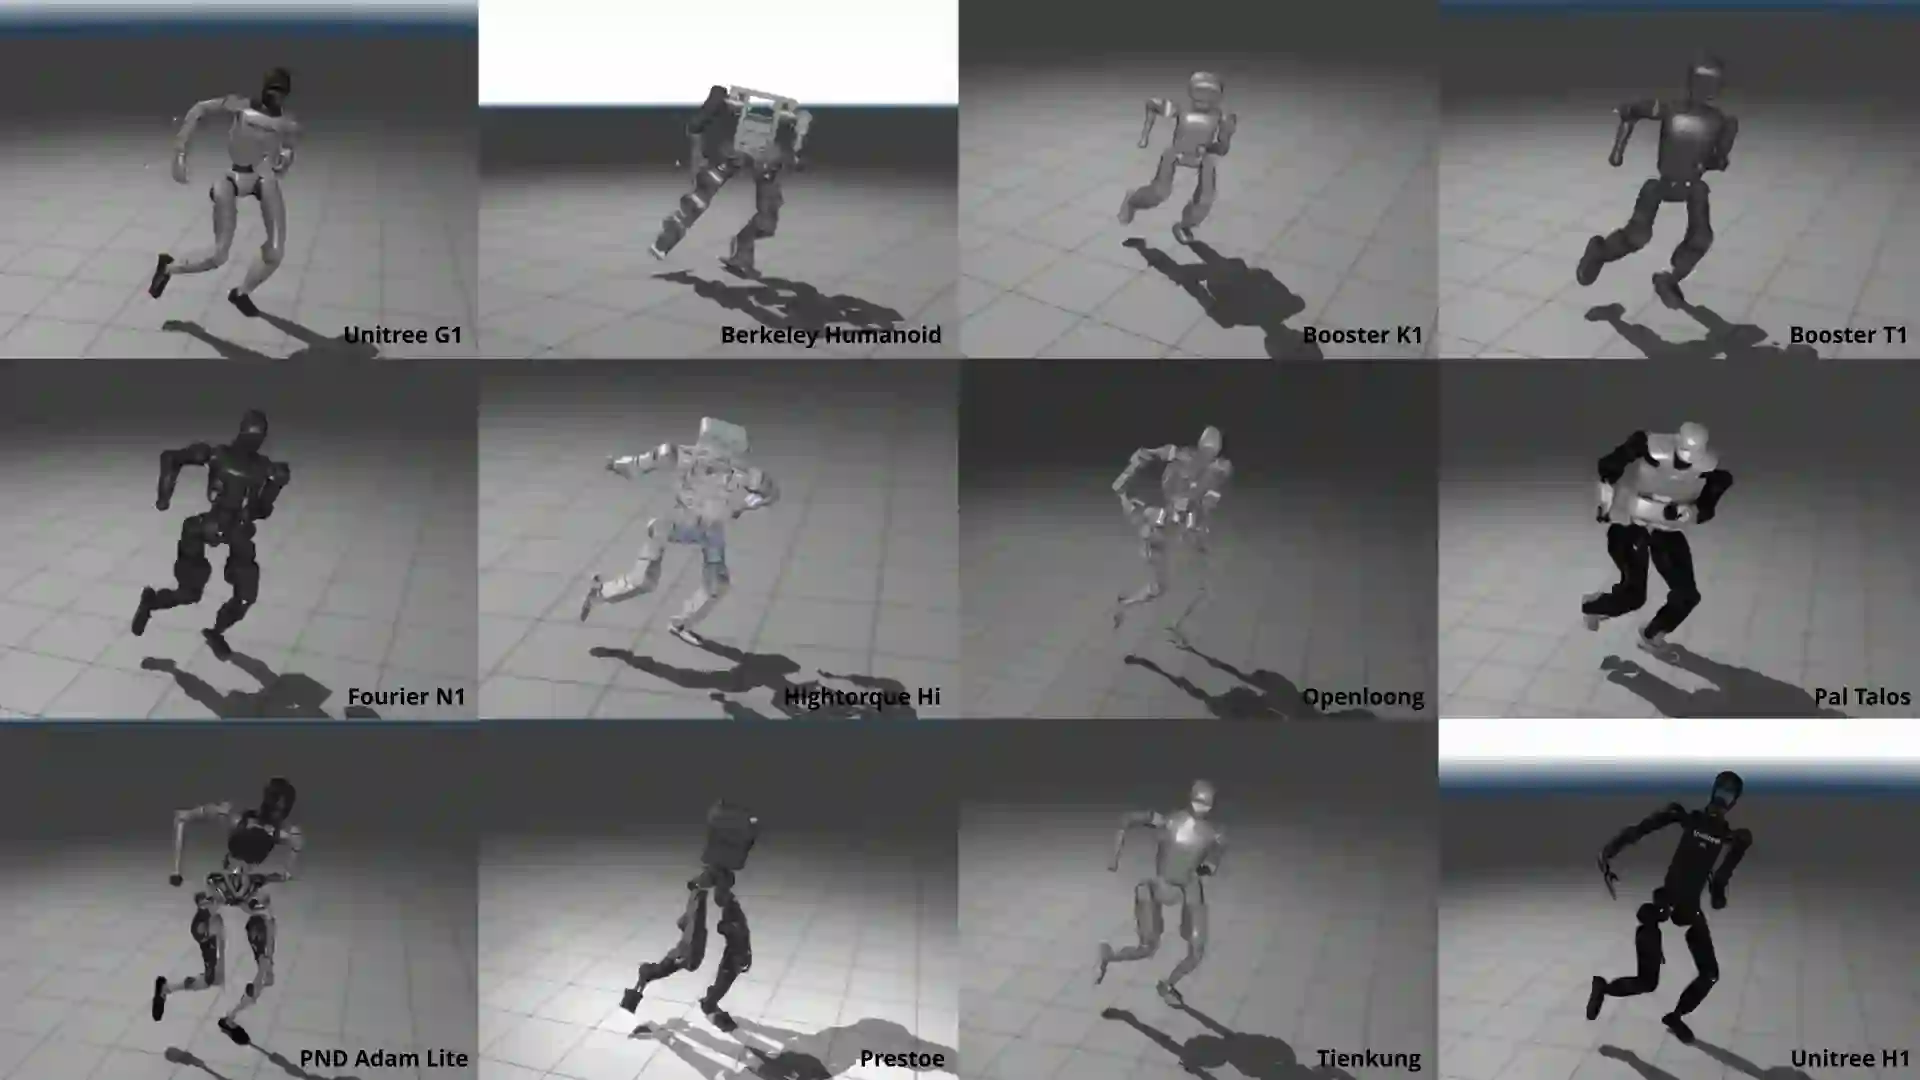
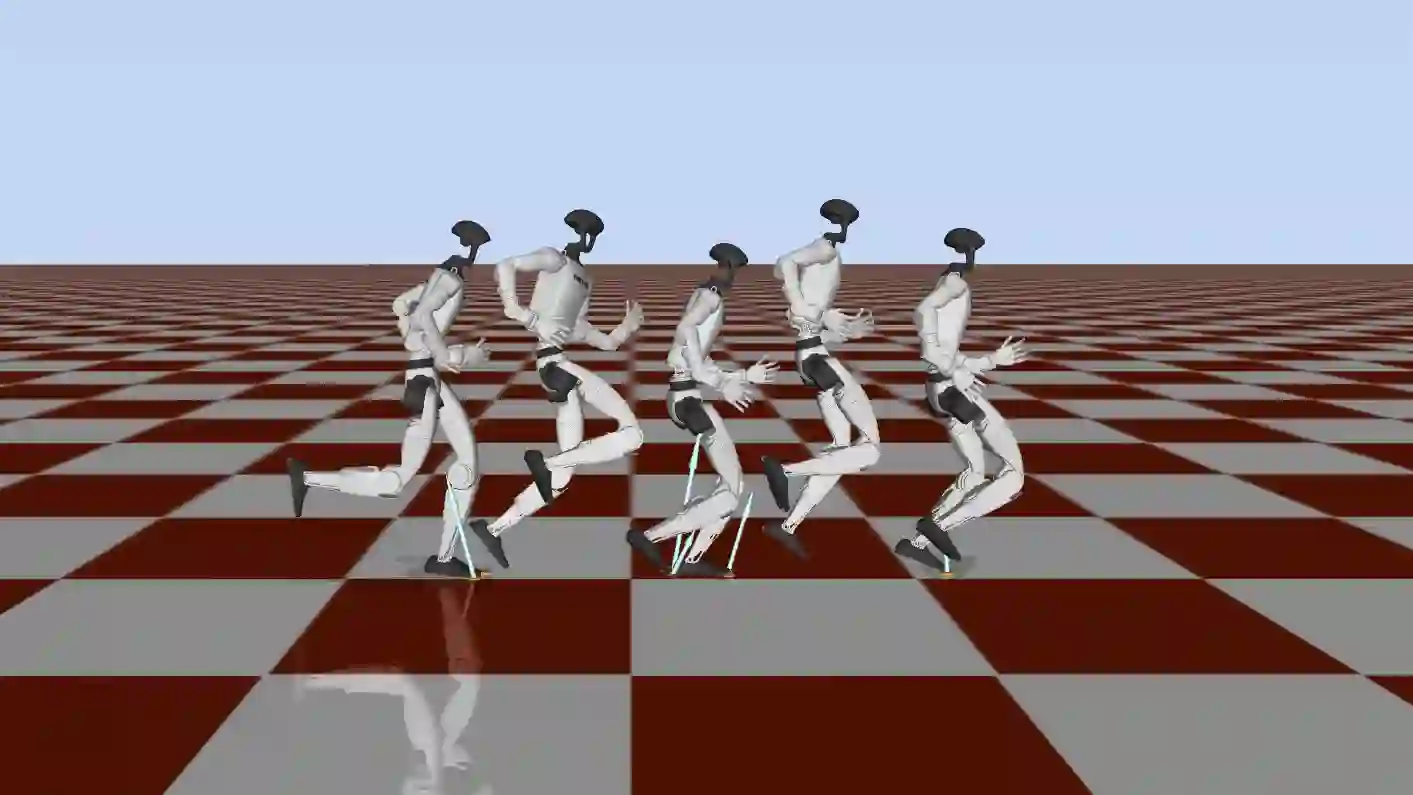
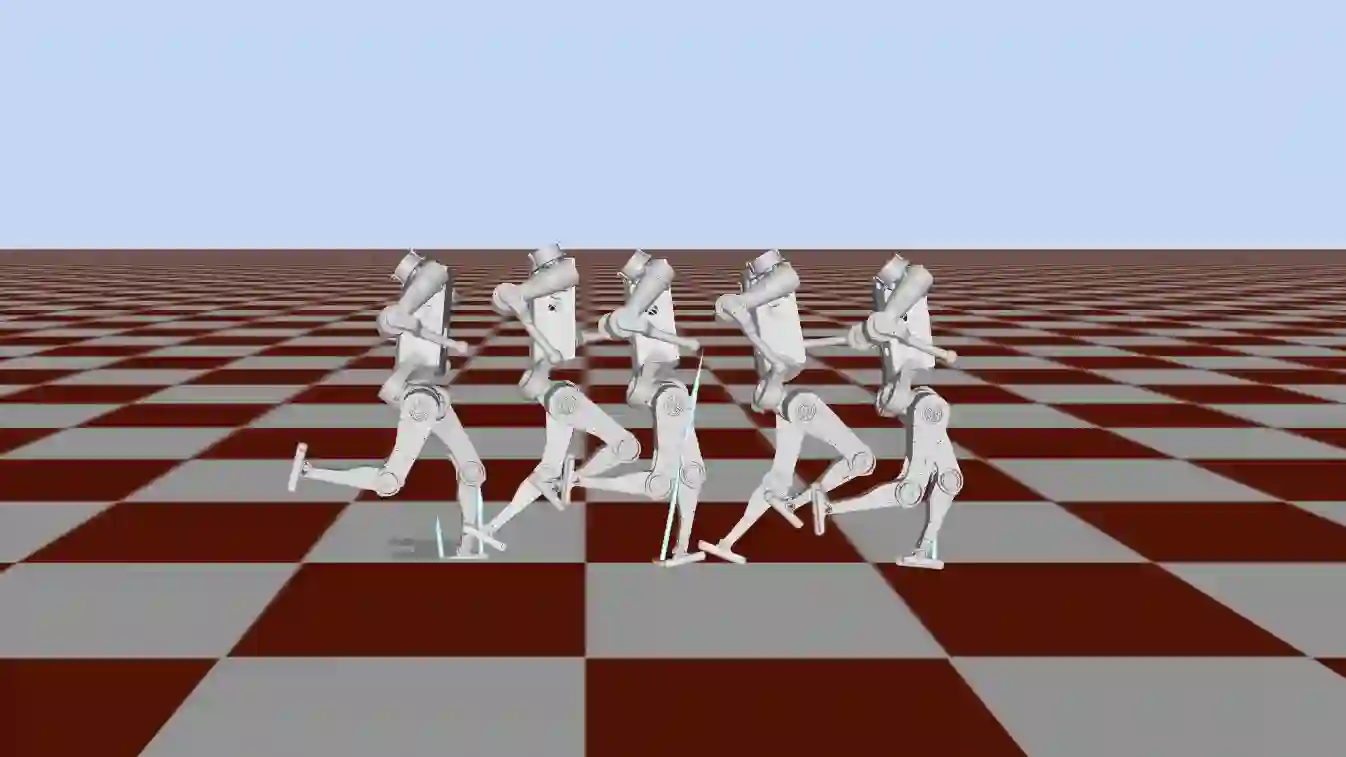
While large-scale human motion capture datasets provide a rich source of demonstrations for humanoid robot learning, retargeting the diverse motions to different humanoid robots remains a nontrivial challenge. Existing kinodynamic trajectory optimization pipelines are computationally expensive and often require manual adjustments per motion. We present FRDV (Fast Retargeting with Dynamics Validation), a scalable framework consisting of rapid constrained kinematic retargeting and an additional dynamics validation pipeline. Its kinematic stage integrates a custom Sequential Quadratic Programming solver, Real-Time Iteration, and parallel chunk-based processing, achieving up to 9,156 frames per second, approximately up to 136 times faster than GMR and ProtoMotions, while robot-specific constraints are incorporated into the optimization to reduce common retargeting artifacts, such as ground penetration and self-collision. For motions requiring additional verification, a contact implicit iLQR controller is utilized to test the retargeted reference under full rigid body dynamics. This dynamics-based validation identifies dynamically infeasible motions and refines contact-related artifacts such as foot floating and foot skating. We evaluate retargeting quality by training motion tracking reinforcement learning policies using several state-of-the-art pipelines and comparing their tracking fidelity and success rates. Furthermore, sim-to-real transfer is demonstrated on a Unitree G1 humanoid. Videos and code are available at: https://daroslab.github.io/frdv/.
翻译:暂无翻译




相关内容




 微信扫码咨询专知VIP会员