

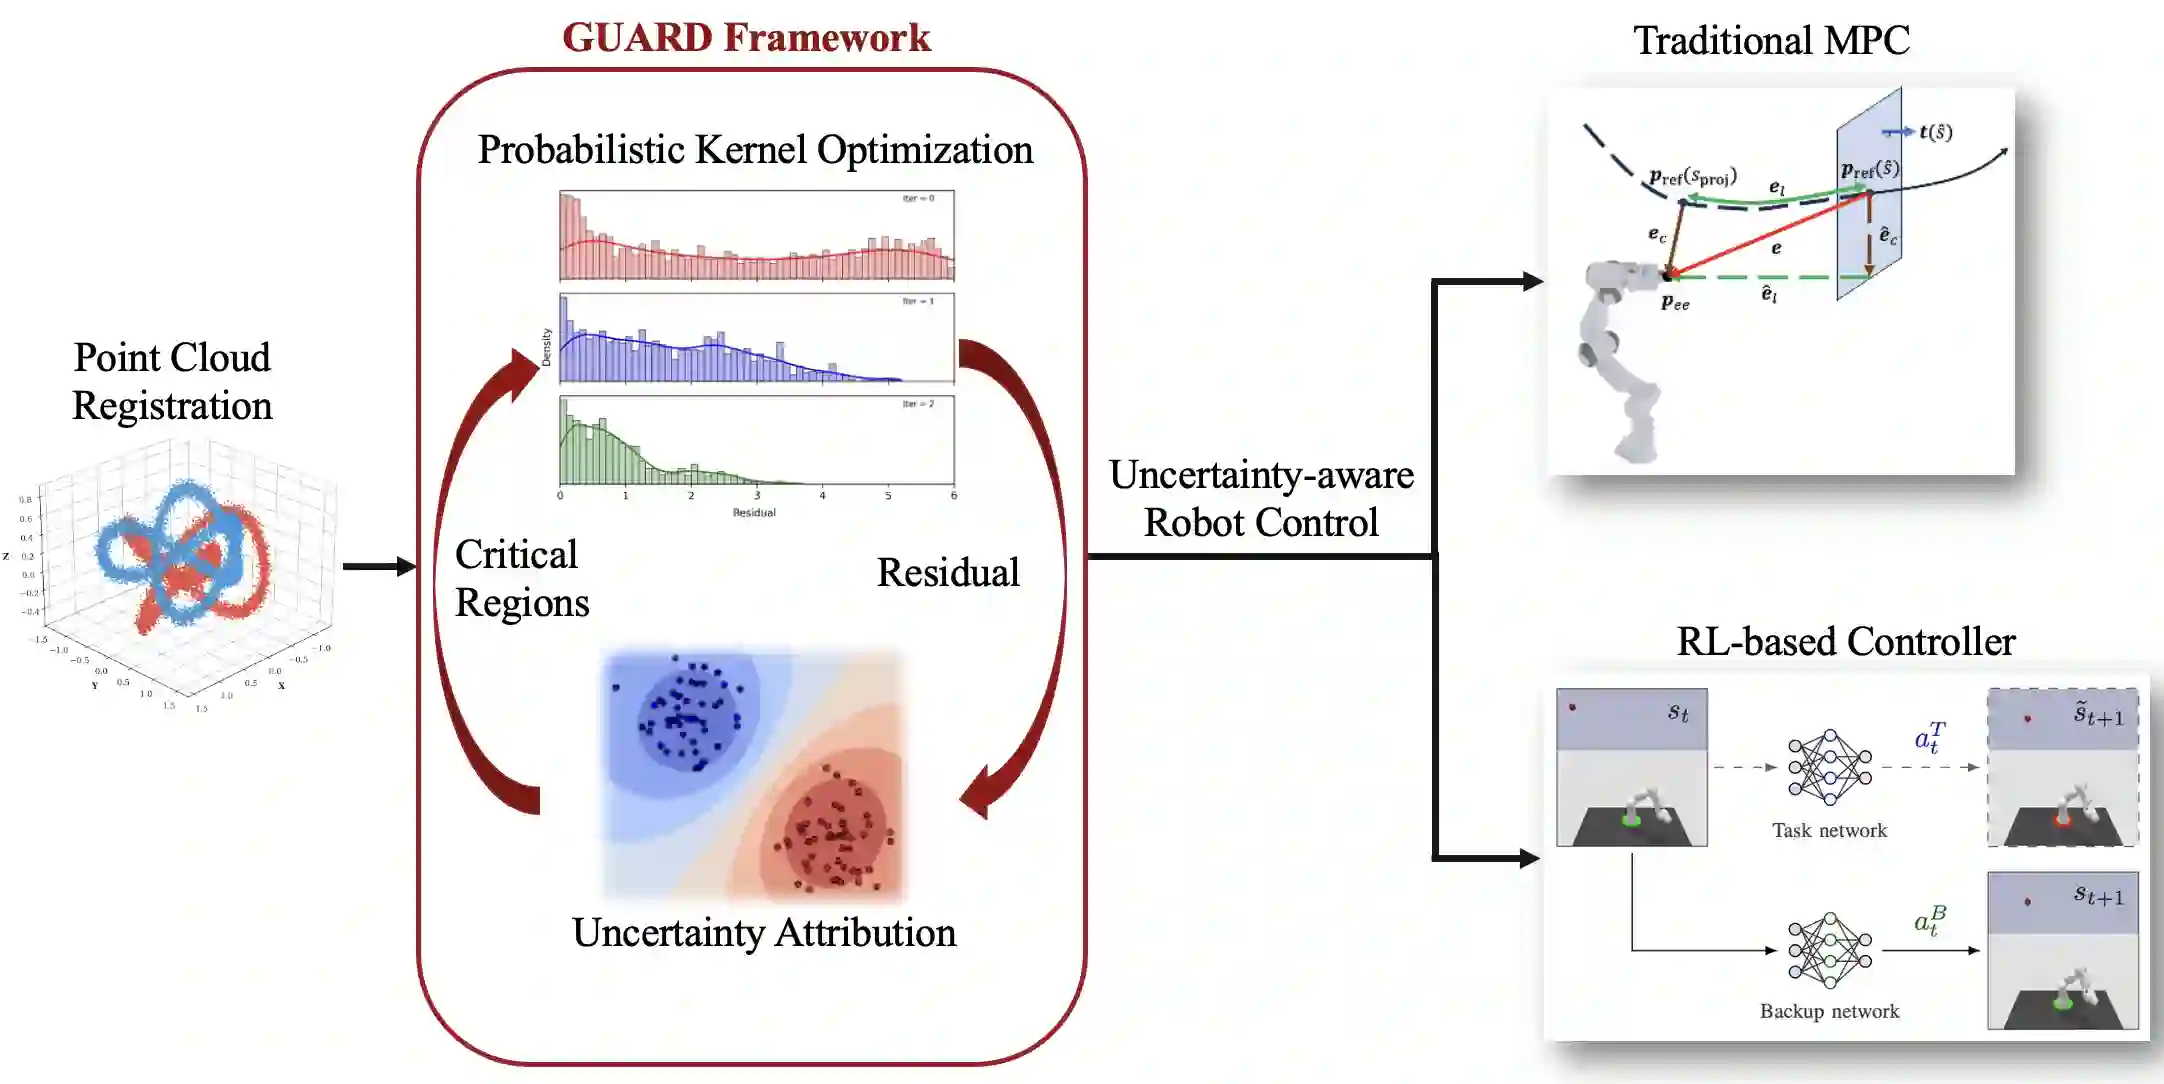
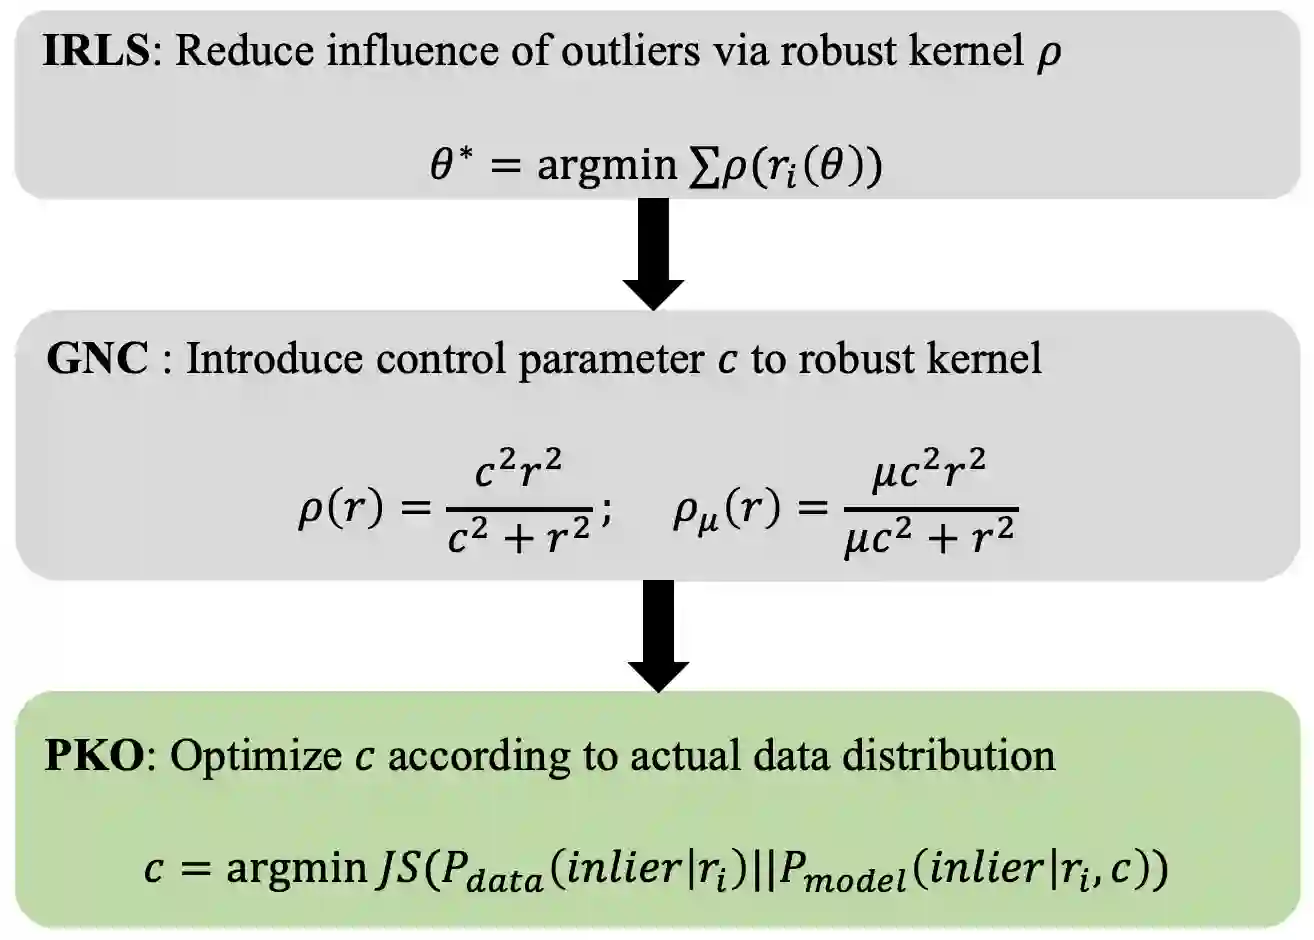
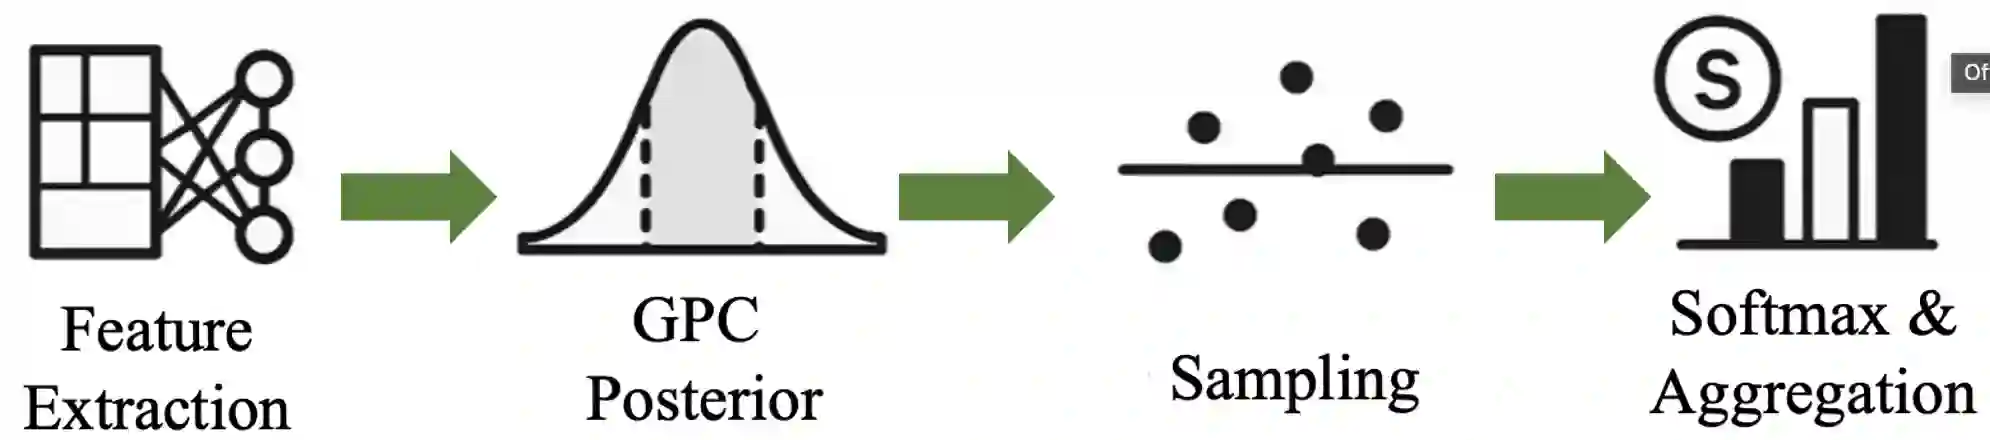
This paper presents the framework GUARD (Guided robot control via Uncertainty attribution and probAbilistic kernel optimization for Risk-aware Decision making) that combines a technique from probabilistic state estimation with an uncertainty identification method to derive critical thresholds for robot control algorithms. The first part focuses on complementing a method for probabilistic kernel optimization (PKO) by a sensitivity-aware uncertainty attribution technique. Next, the estimated uncertainties and their sources are forwarded to the robot controllers to adapt safety margins and trigger the initialization of safe backup trajectories. To validate GUARD's applicability and performance, experiments are conducted on a traditional model predictive control (MPC) algorithm and a reinforcement learning (RL) based controller. The results demonstrate that GUARD reduces collision rates by 44-67% in the RL-based evaluation, while decreasing backup policy activation by 50-75% in the medium- and high-uncertainty profiles. In the MPC simulation, GUARD successfully avoids collisions. By unifying the probabilistic kernel optimization algorithm from robot state estimation with the uncertainty estimation method for learning-based control, GUARD brings together traditional techniques and learning for safe and efficient robot applications.
翻译:暂无翻译


相关内容



 微信扫码咨询专知VIP会员